Humanoid Shoulder
Key contributions
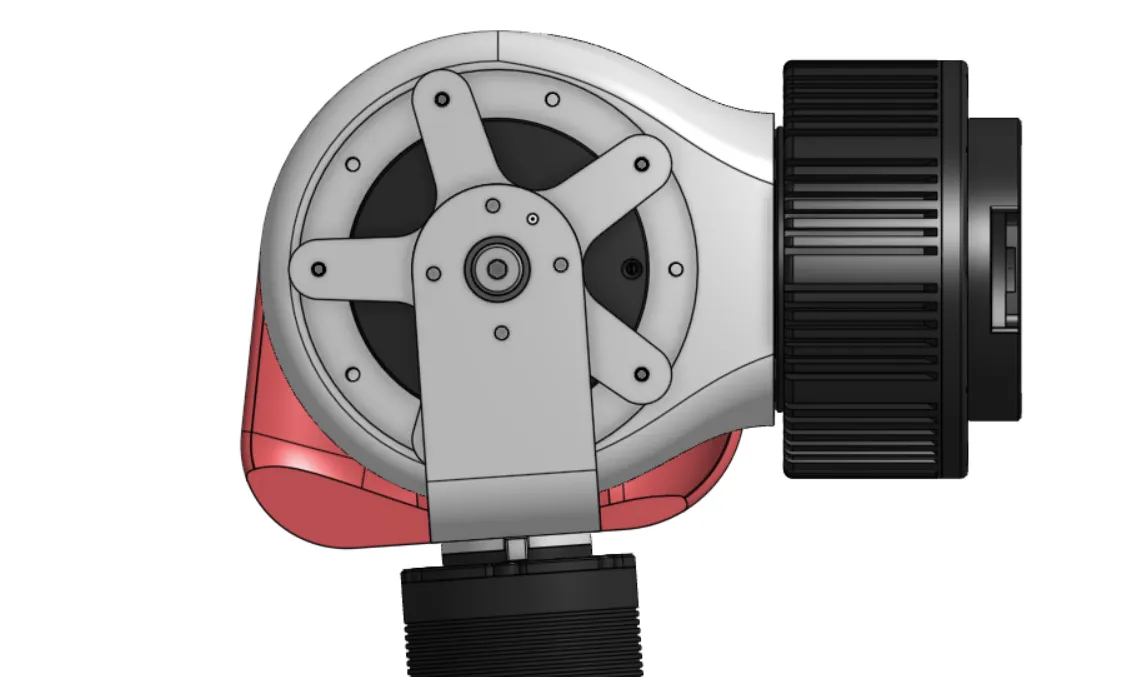
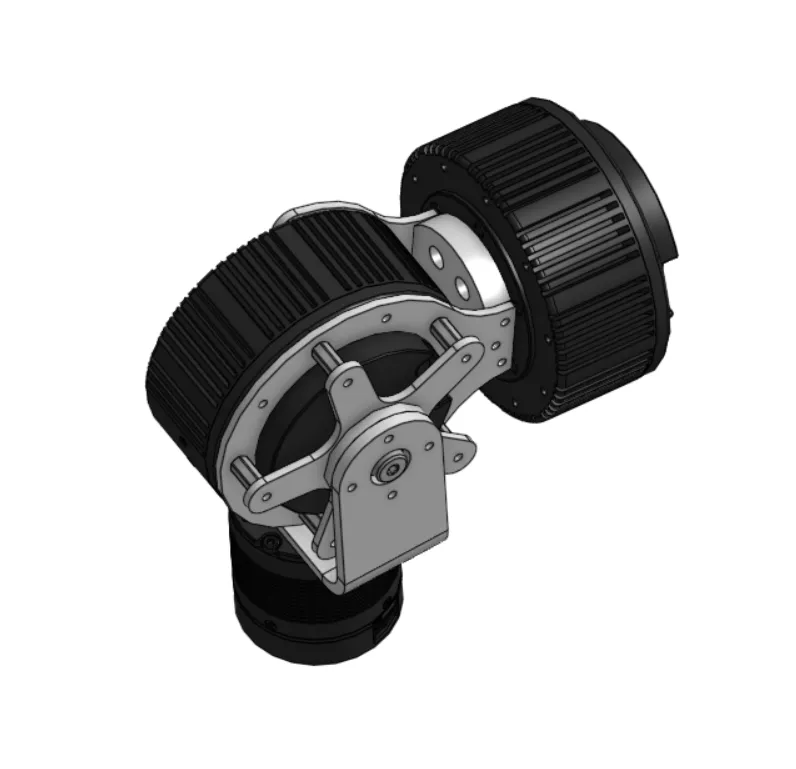
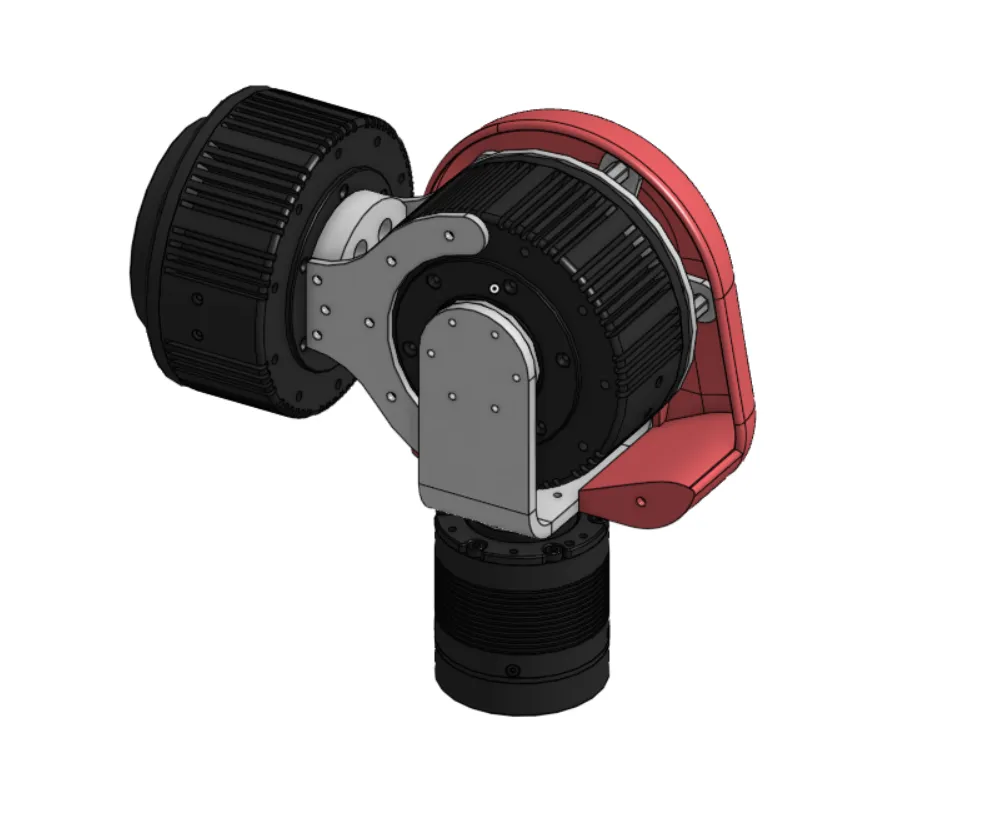
High-torque shoulder design. Co-designing a high-DOF shoulder assembly engineered to withstand a 25 Nm peak static torque while supporting a 6 kg total load (4 kg arm mass + 2 kg payload) at full horizontal extension.
Multi-material structural engineering. Executing material selection strategies utilizing 6061 aluminum for primary structural brackets and 304 stainless steel for high-wear shafts and load-bearing interfaces.
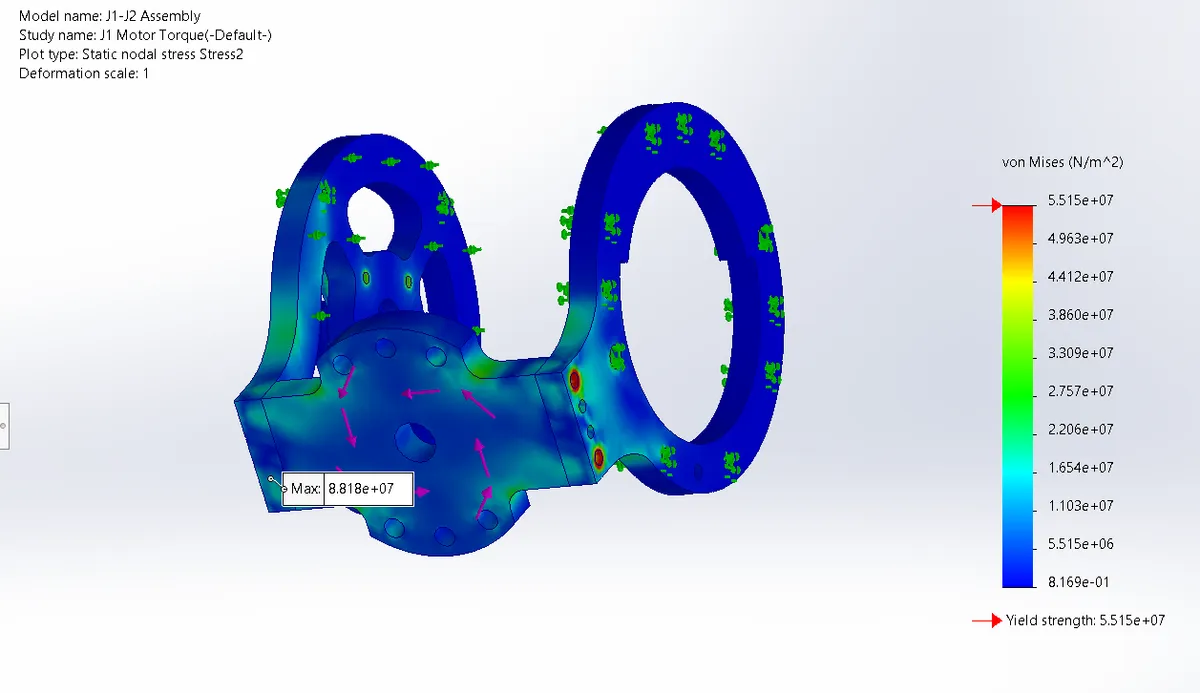
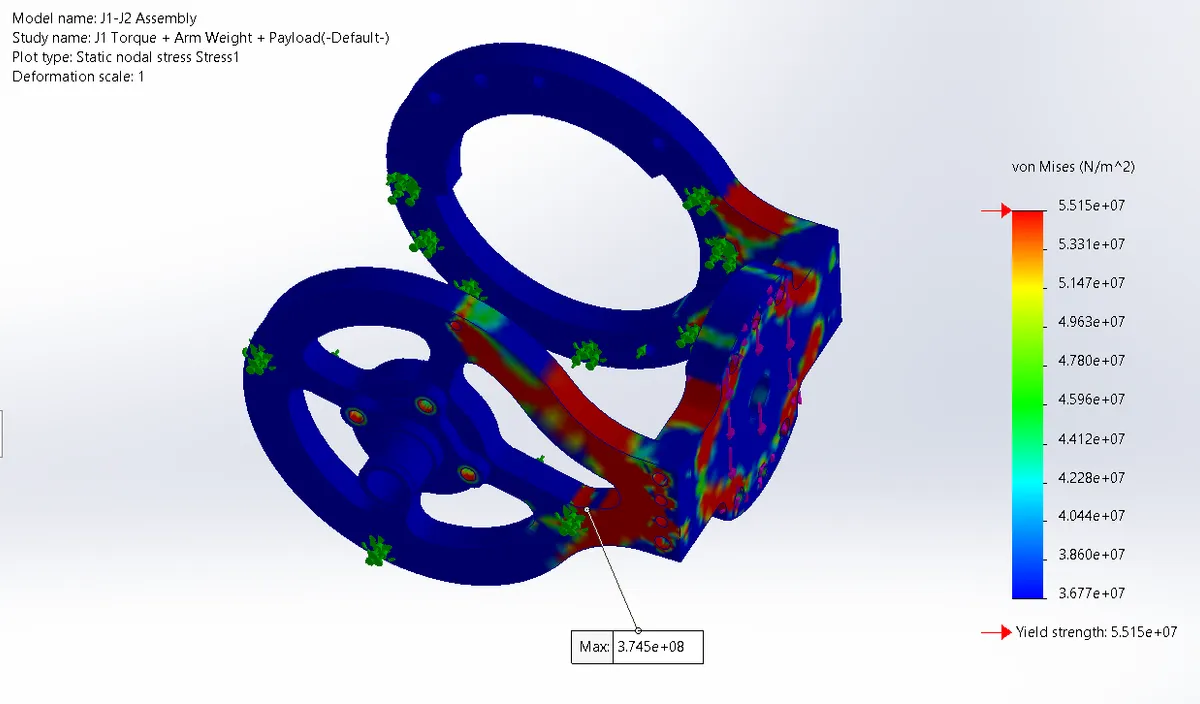
FEA-driven optimization. Validating component geometry via finite element analysis to optimize part thicknesses, ensuring a high strength-to-weight ratio and maintaining structural integrity under maximum loads.
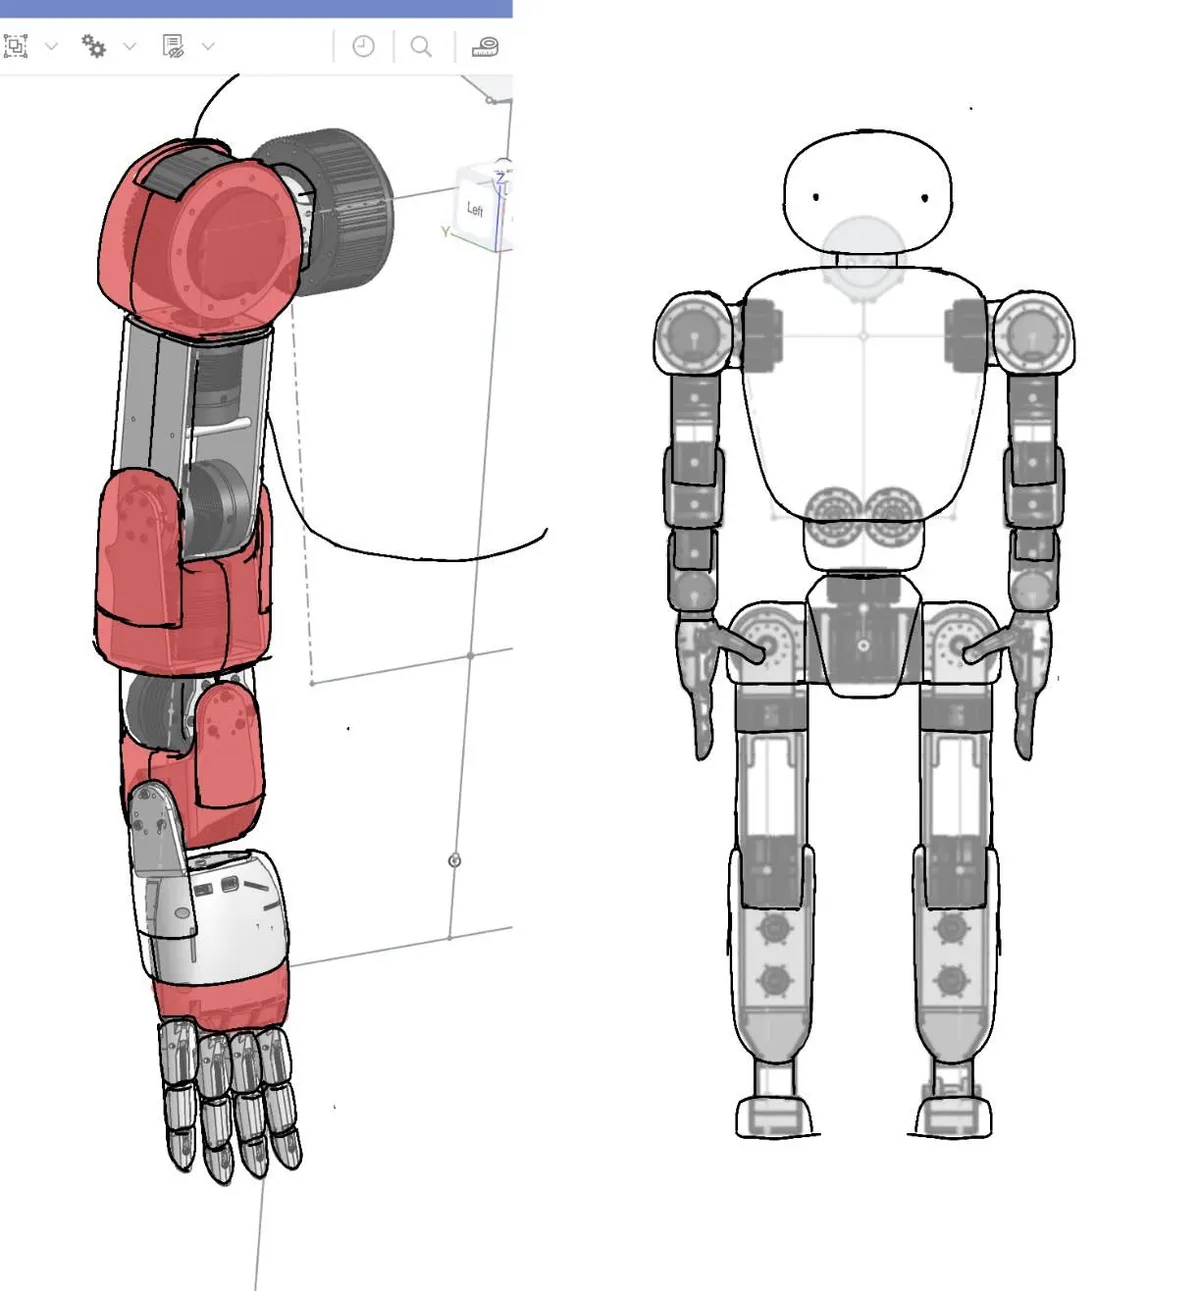
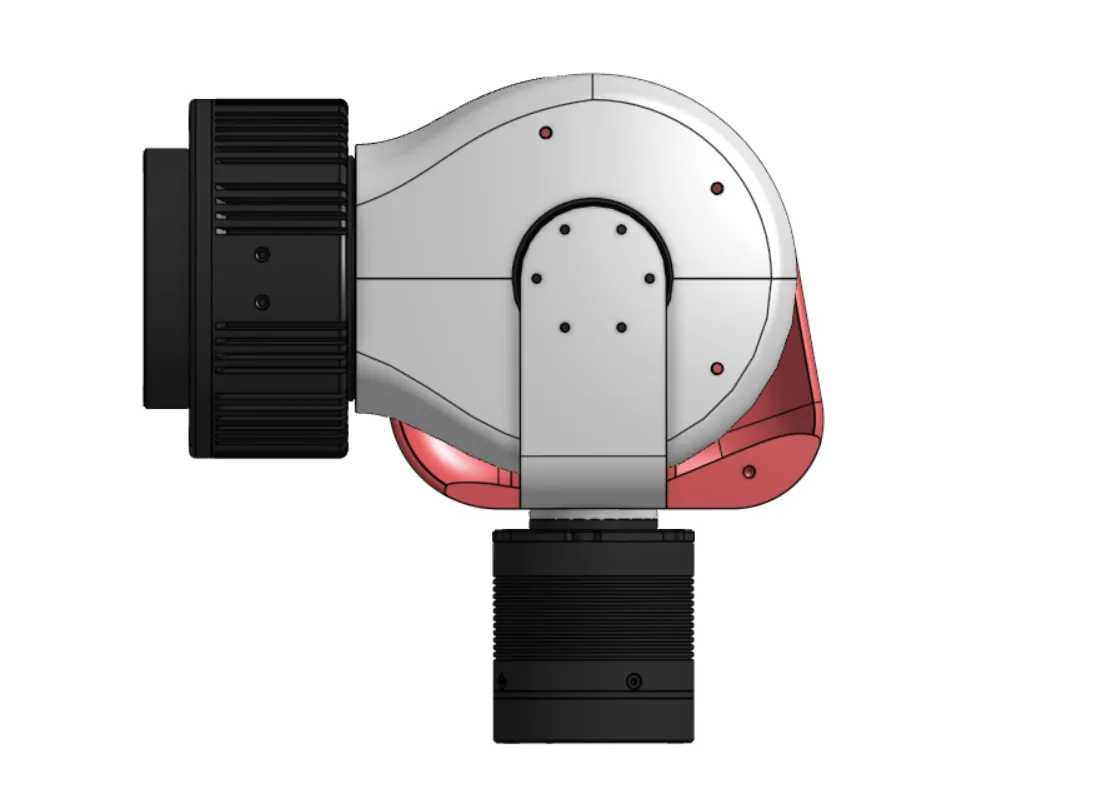
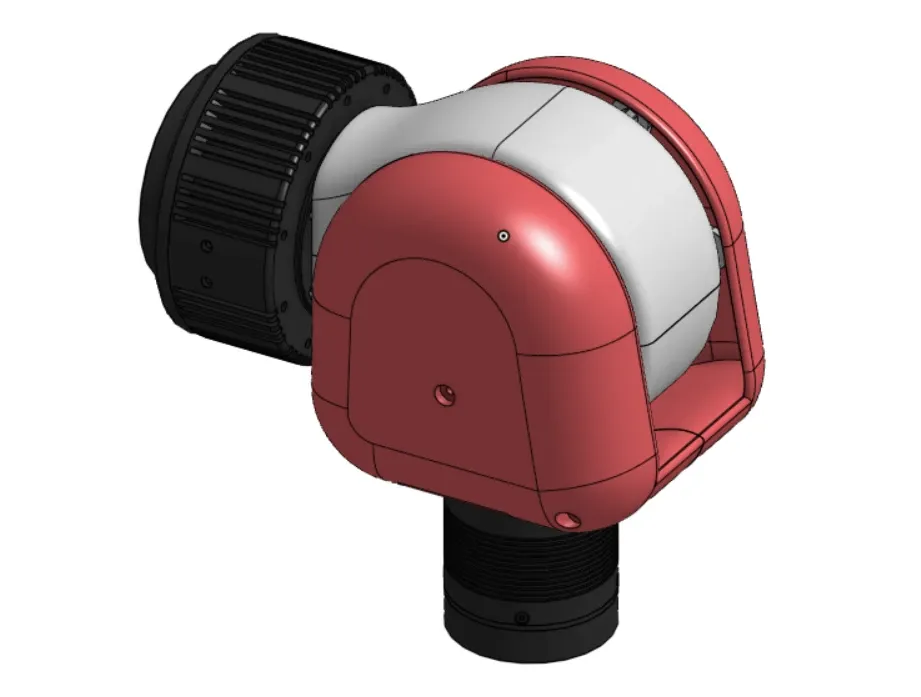
Full-body industrial design. Leading the design of the robot’s exterior casing and aesthetic shell, ensuring seamless integration between structural components and protective housing.
Cross-functional CAD coordination. Collaborating within a 3-person sub-team (under a 10-person arm division) to manage complex Onshape assemblies, ensuring precise mechanical interfaces with the electrical, torso, and leg subsystems of the full humanoid platform.