Berry Gentle
Key contributions
Concept initiation and funding. Authored a successful grant proposal for the Borgen Design Fund, securing funding to develop a compliant end-effector aimed at reducing fruit bruising in automated fresh-market apple harvesting.
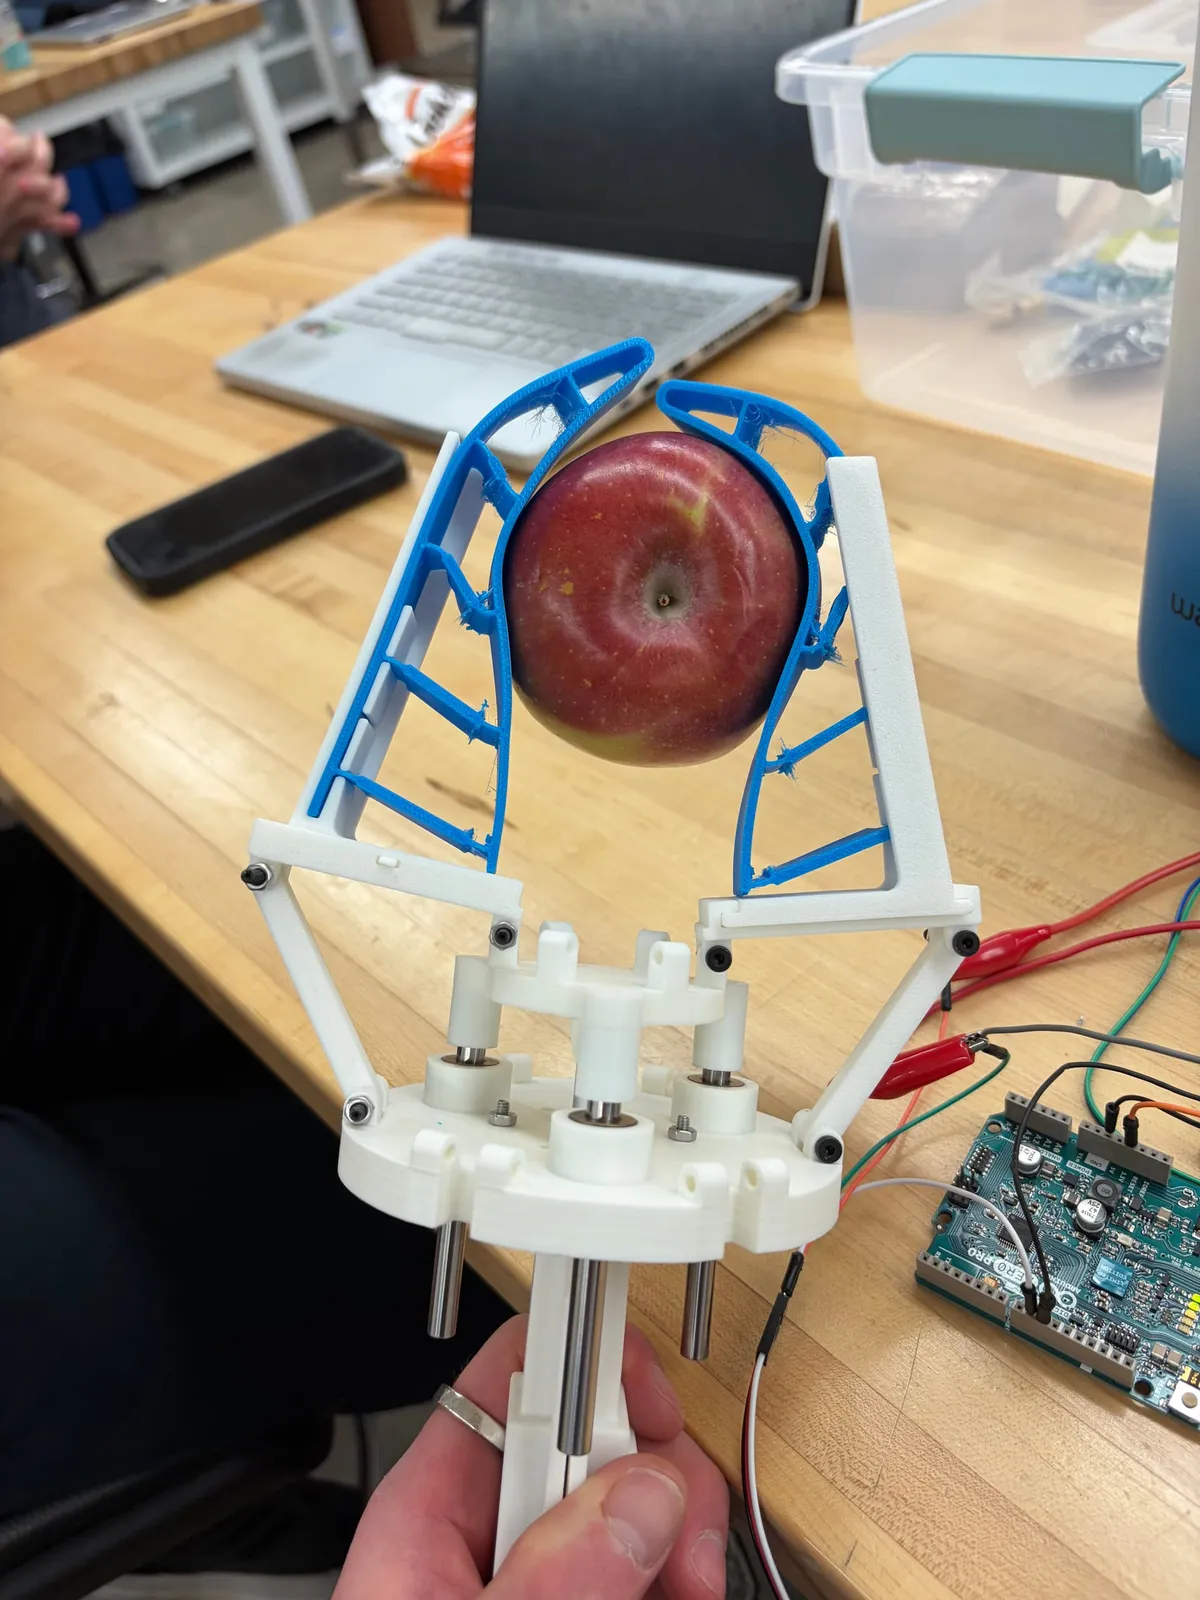
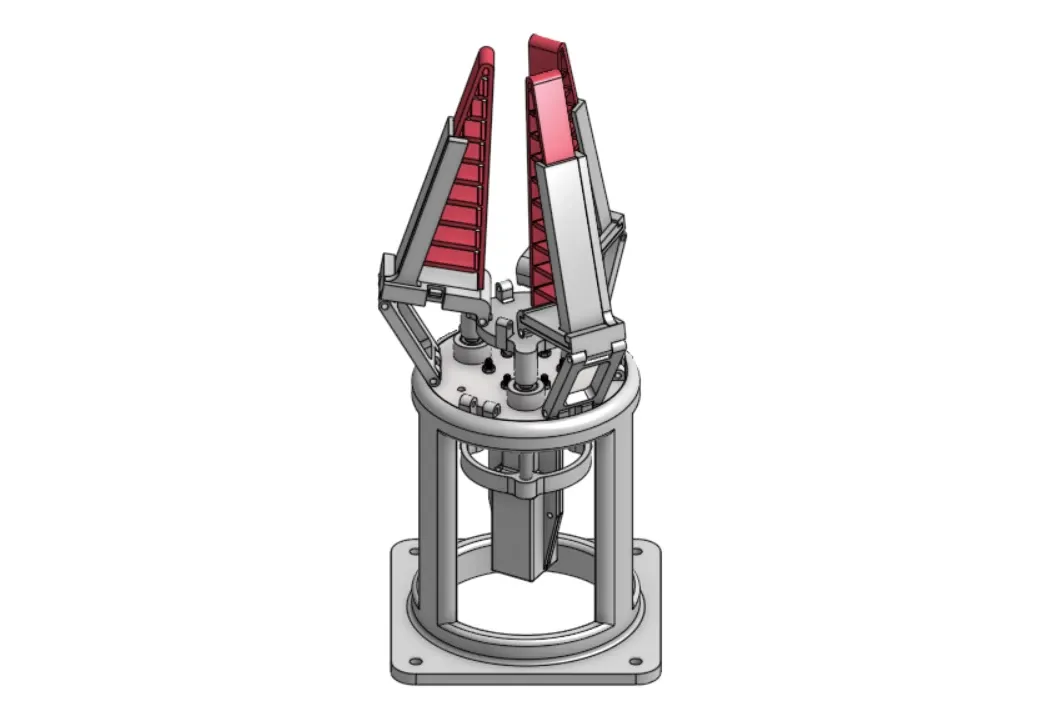
Compliant mechanism design. Engineered a Fin-Ray-inspired soft robotic gripper utilizing passive compliant geometry to naturally conform to varying fruit morphologies, eliminating the need for expensive high-fidelity sensor arrays.
Actuation system development. Designed a custom linear actuation assembly integrating 3D-printed TPU/PLA components with off-the-shelf hardware to drive the gripper’s closing kinematics.
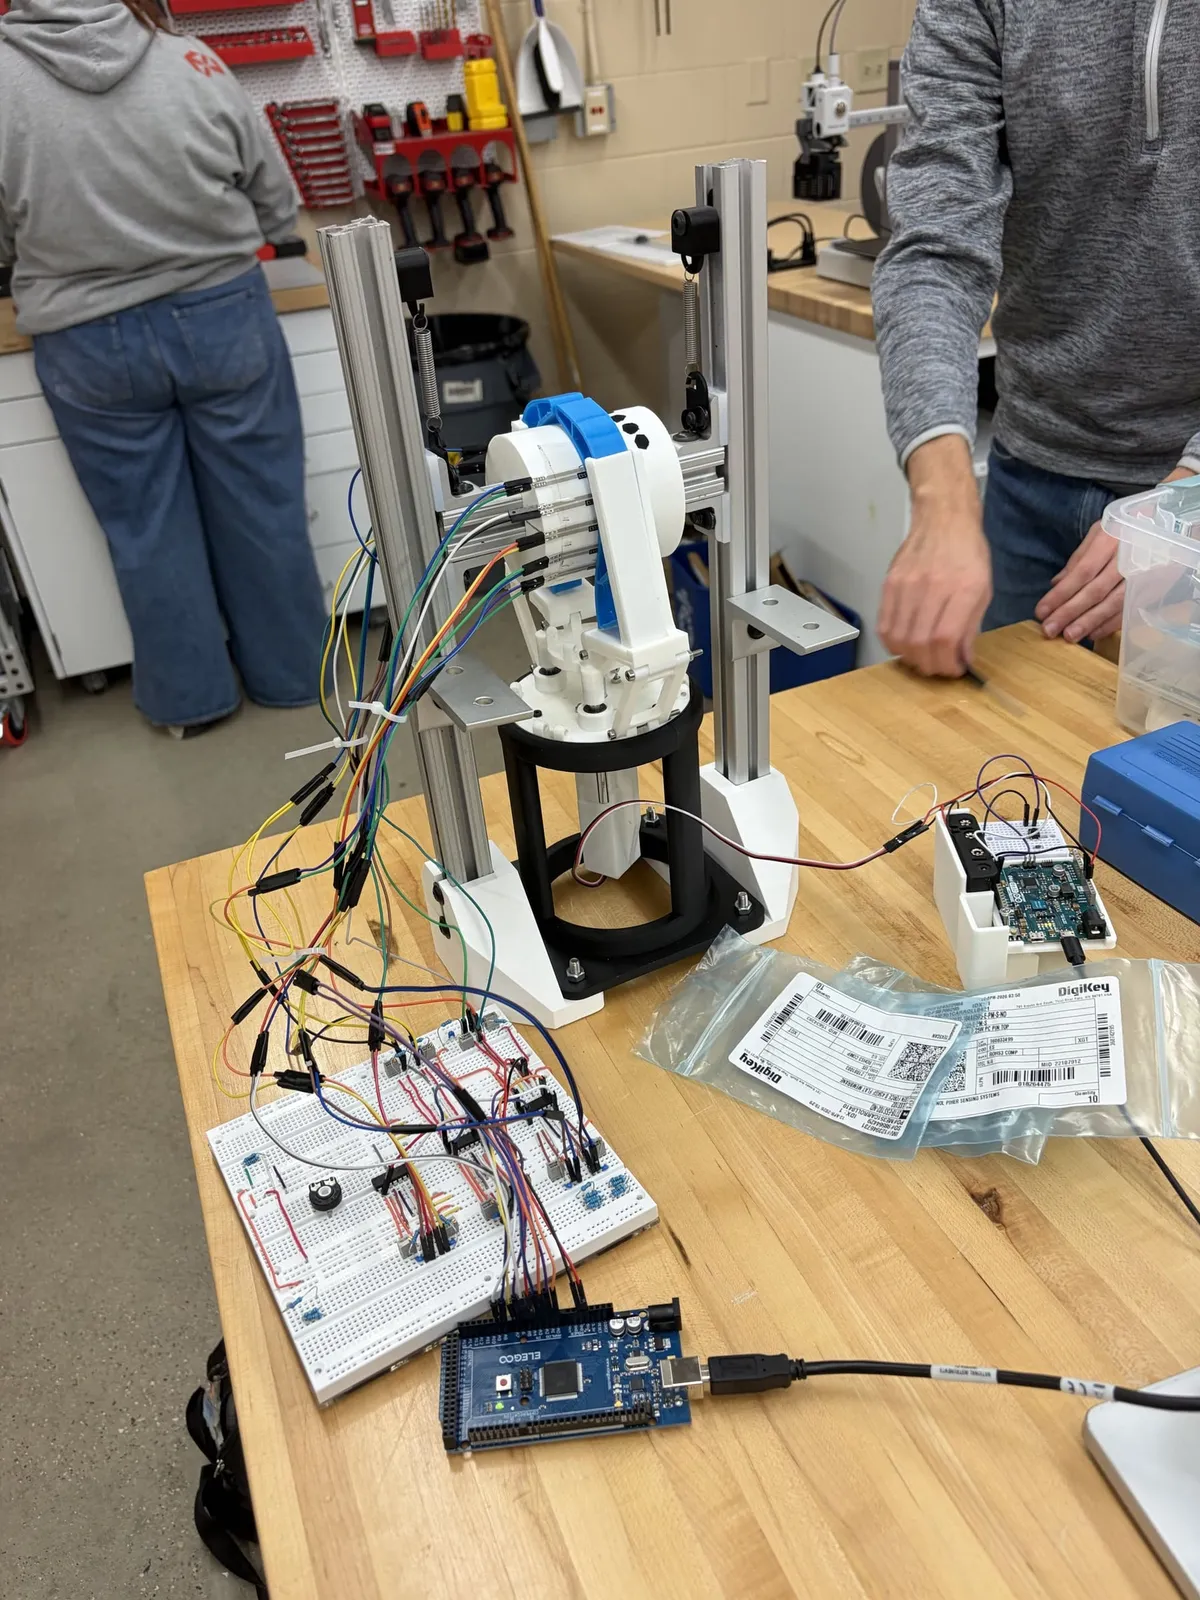
Experimental testbed engineering. Developed a specialized 80/20 structural test rig featuring a spring-loaded sliding carriage to measure gripping reliability.
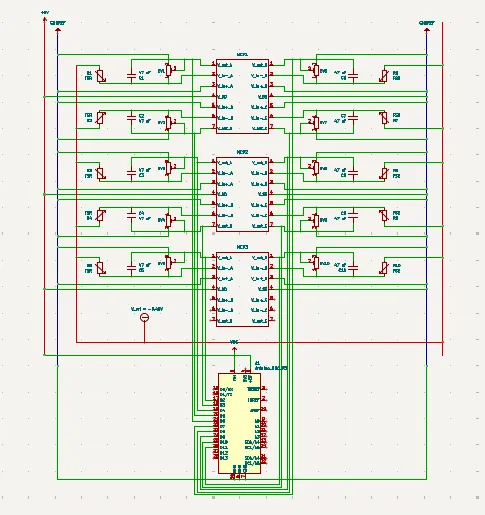
Sensor integration and data acquisition. Designed and wired a multi-point Force Sensitive Resistor (FSR) circuit to map pressure distribution across test cylinders and provide empirical validation for the gripper’s stress-distribution capabilities.
Validation and testing protocol. Helping with the design of experiments (DOE) to evaluate gripper performance and optimize its compliant geometry, collaborating on FEA modeling to correlate physical test results with digital simulations.