Humanoid Legs
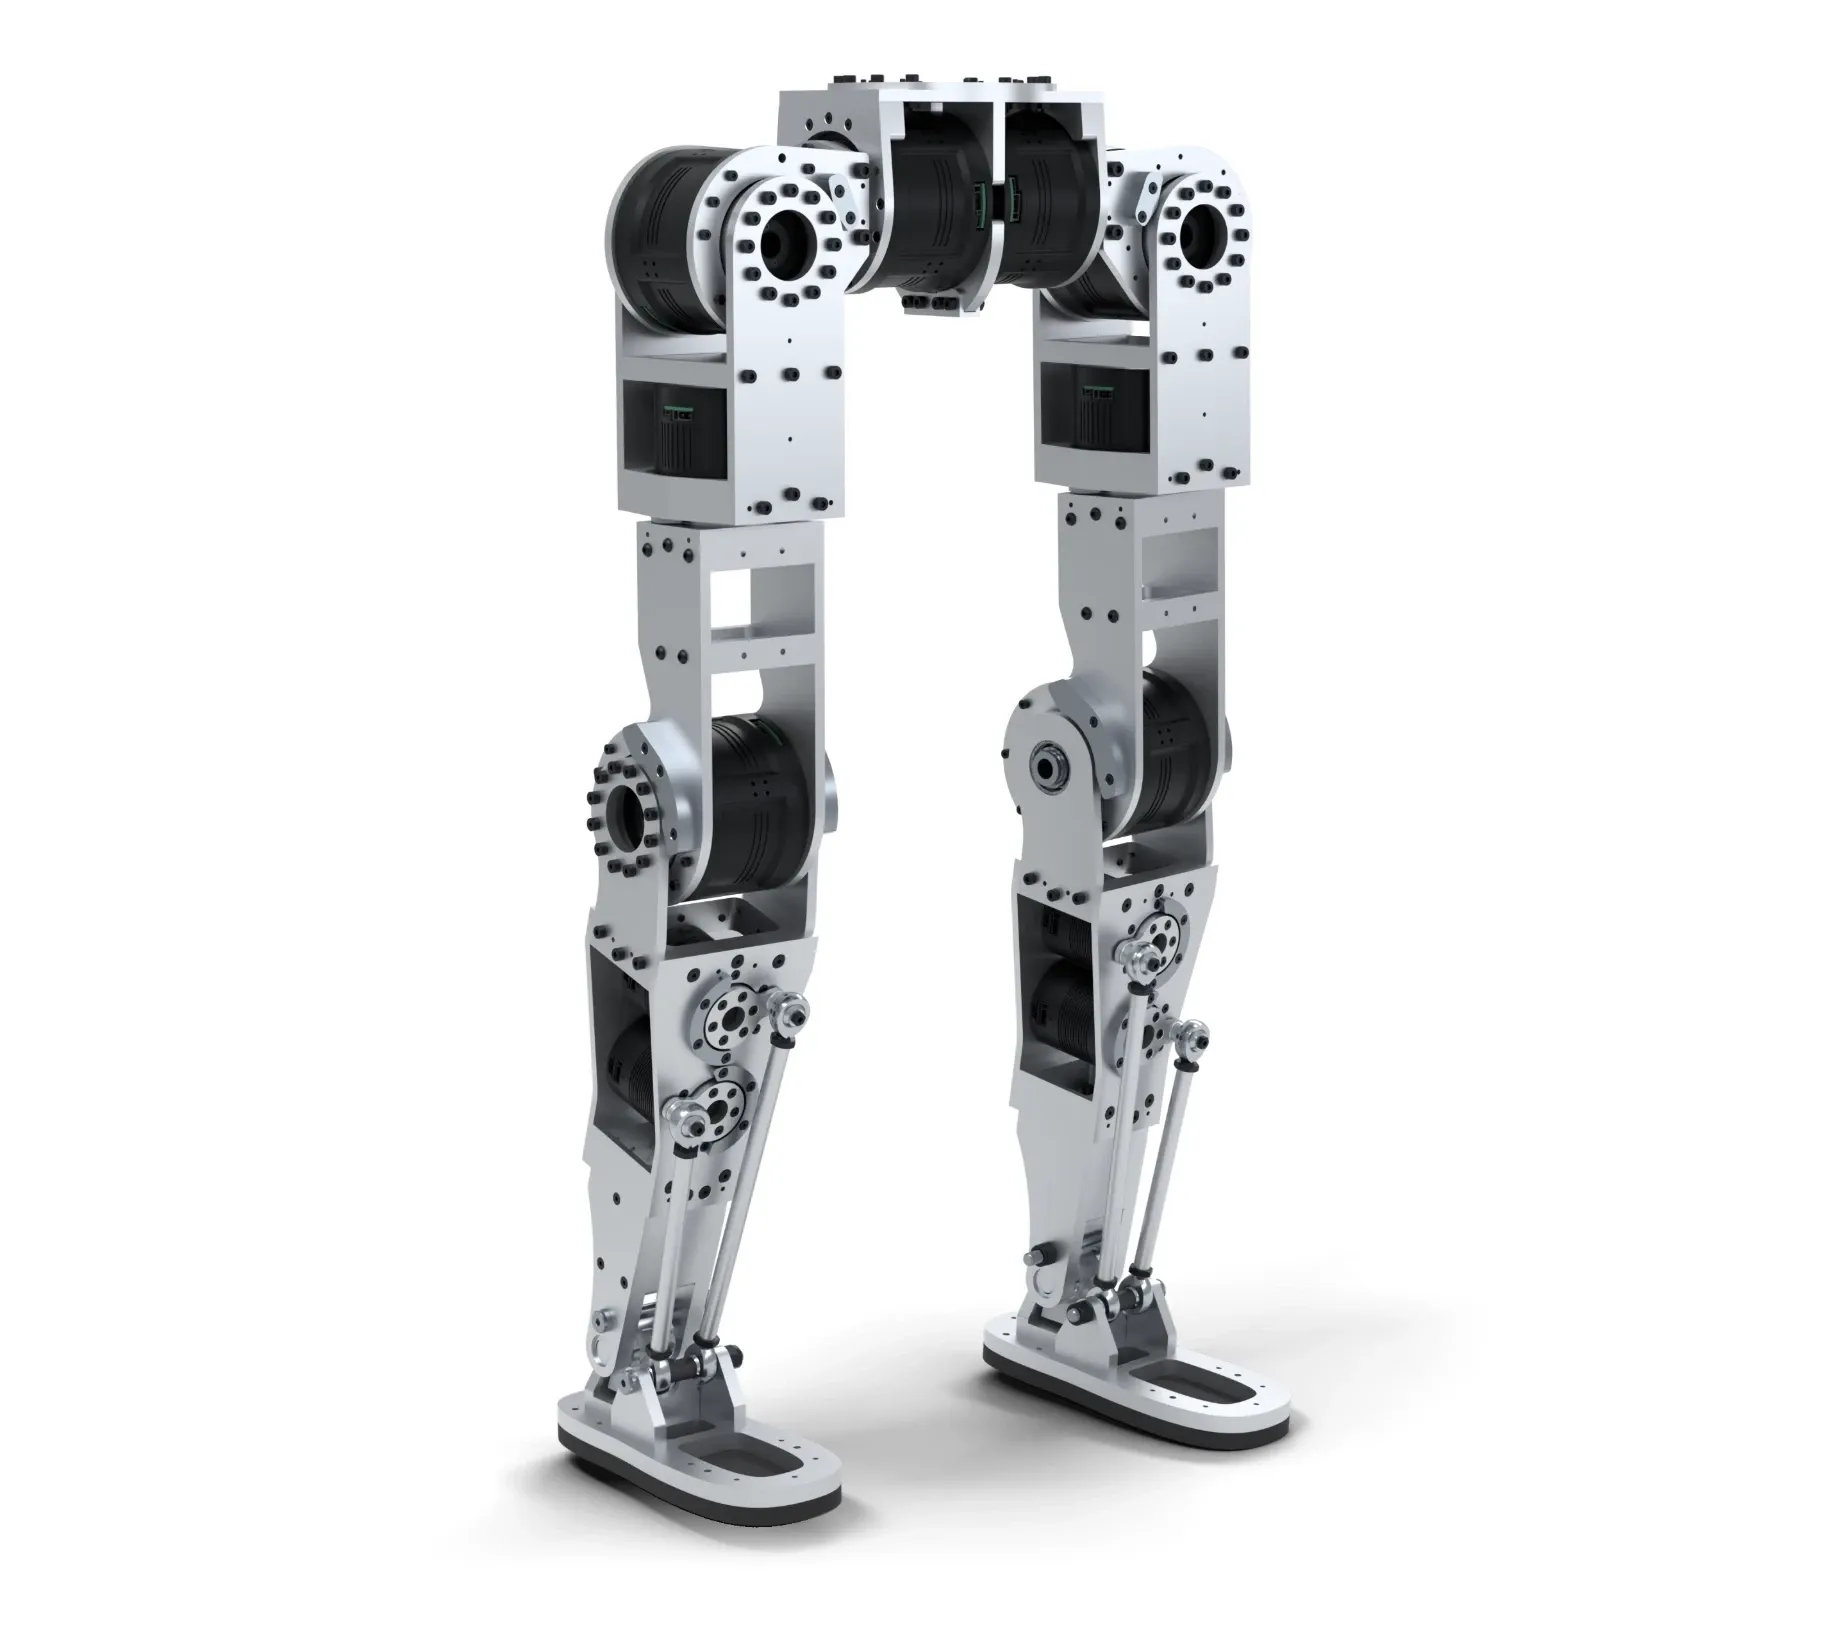
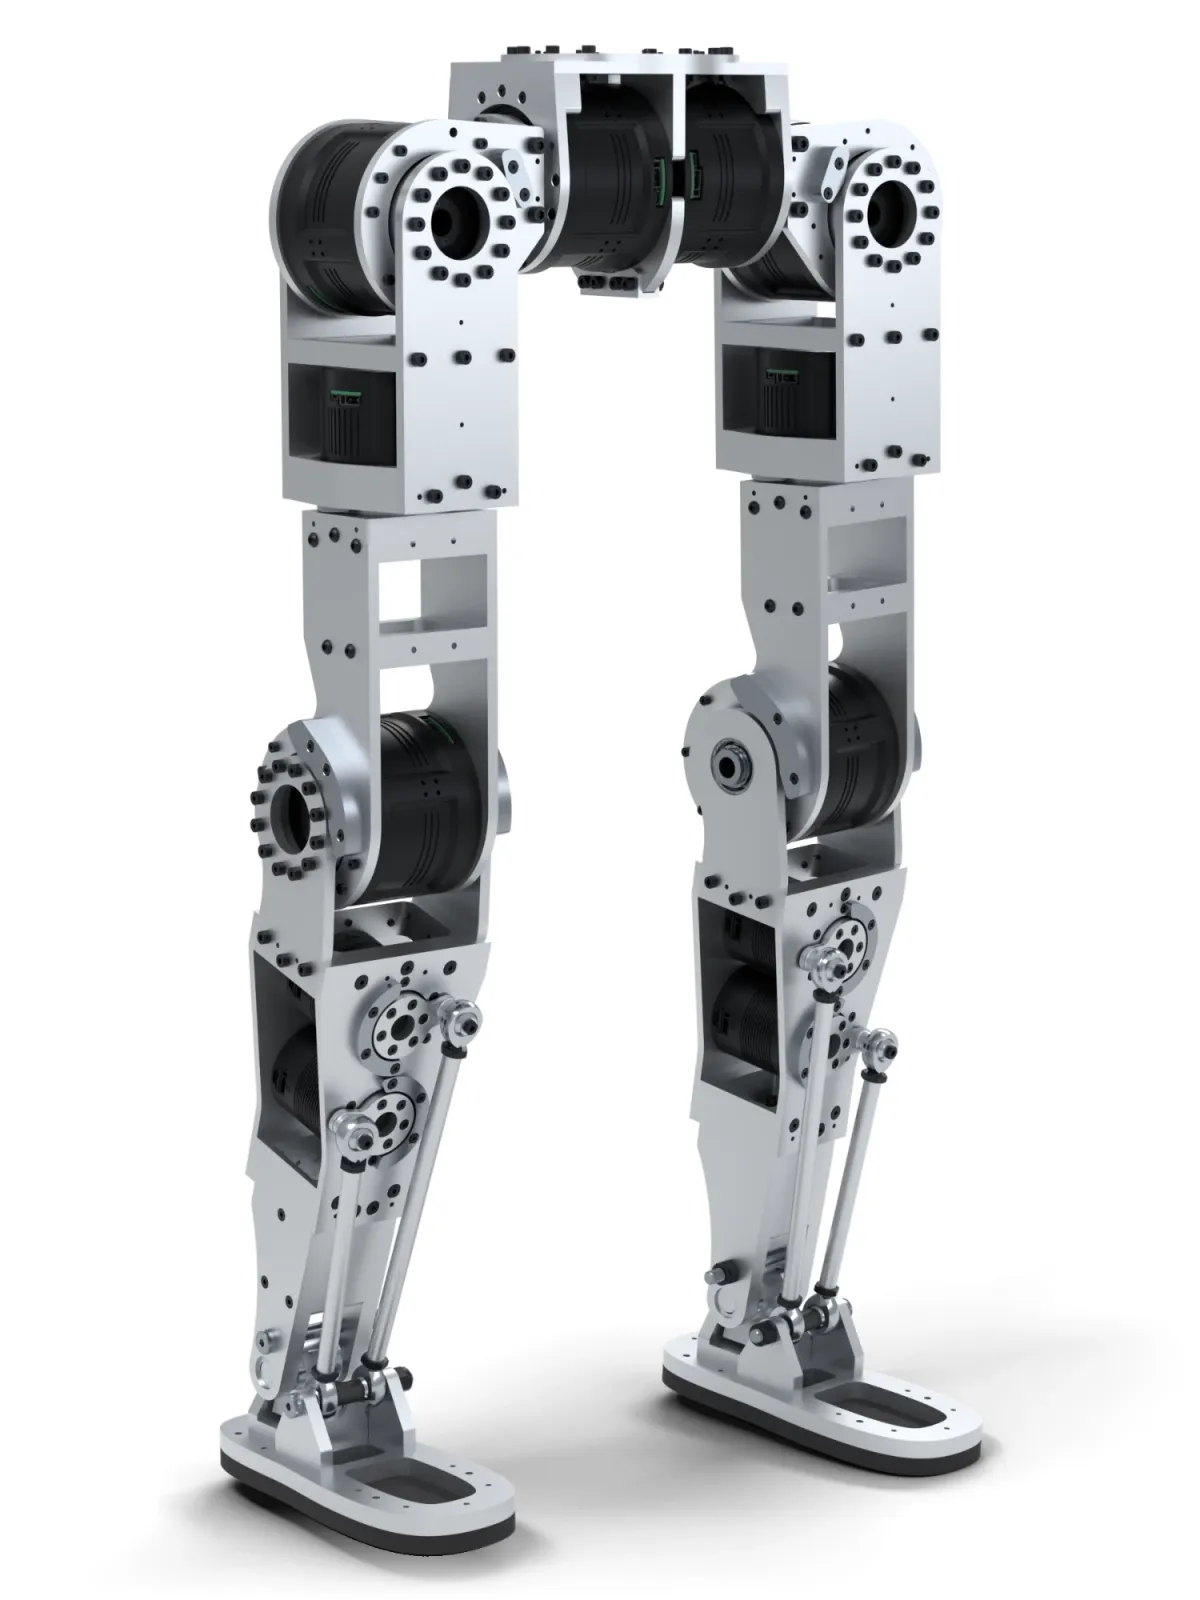
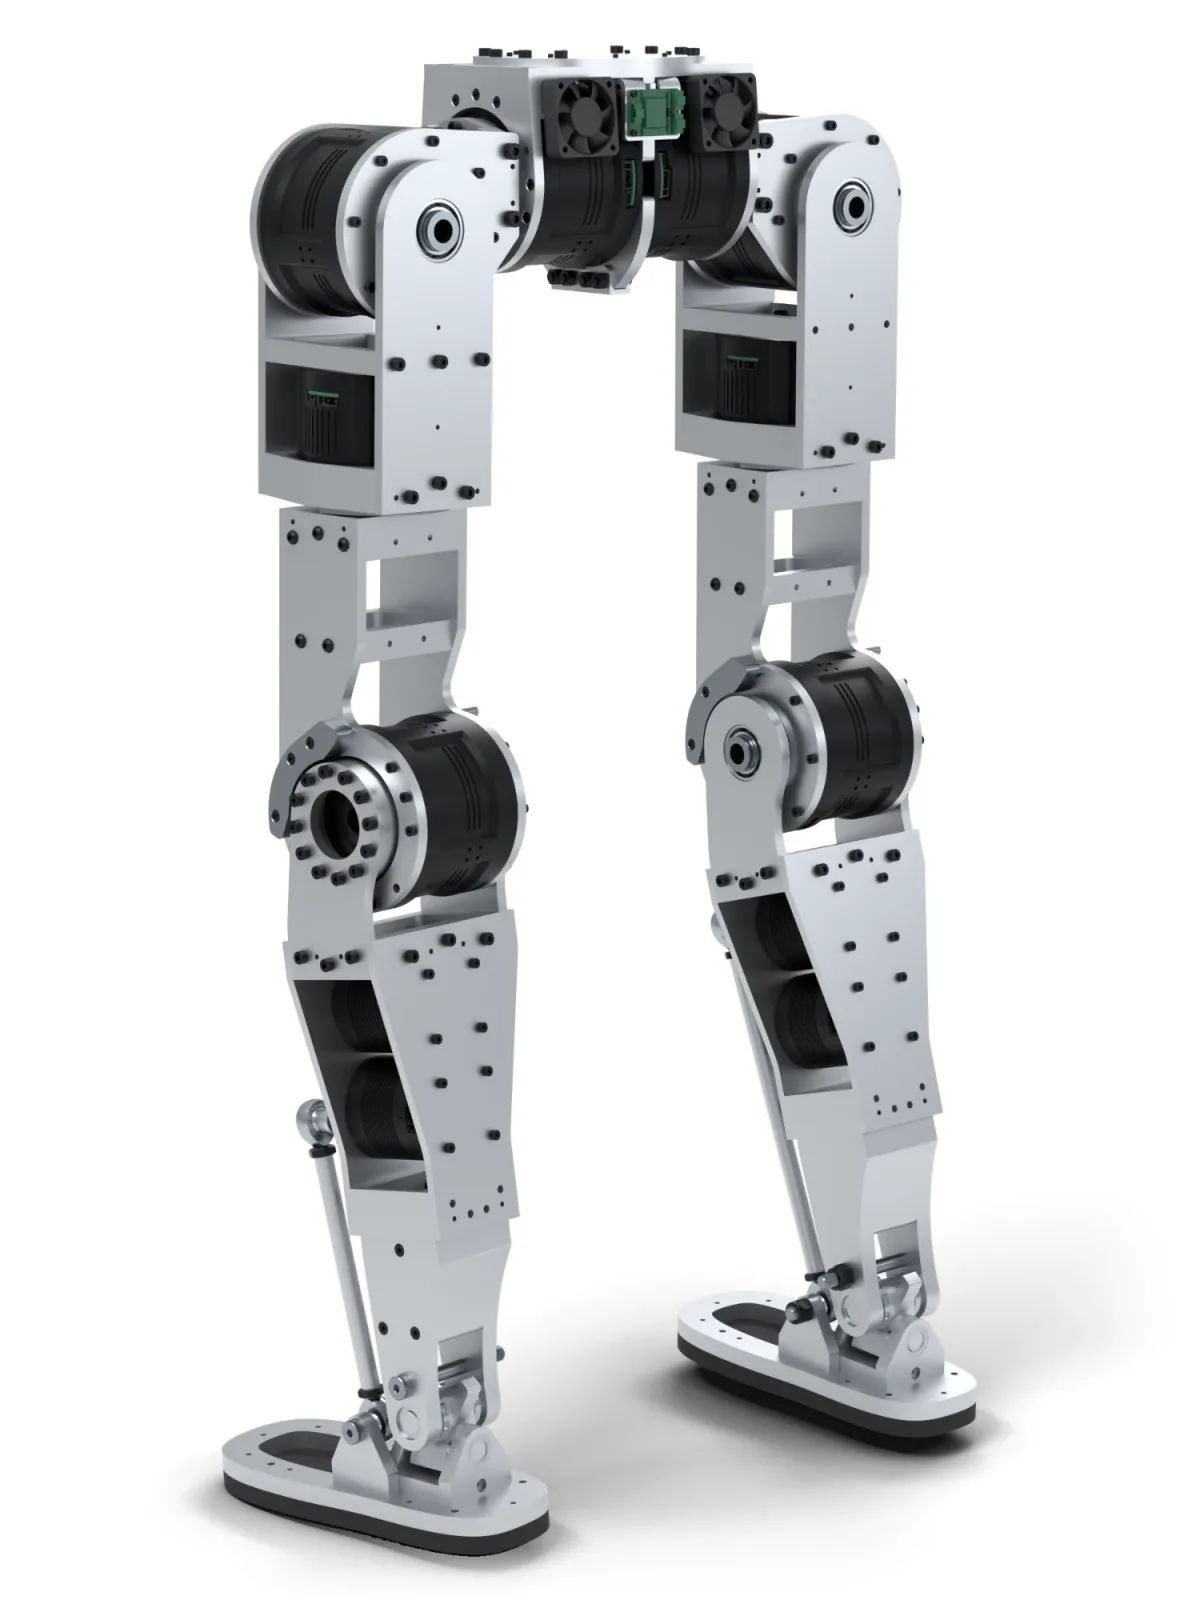
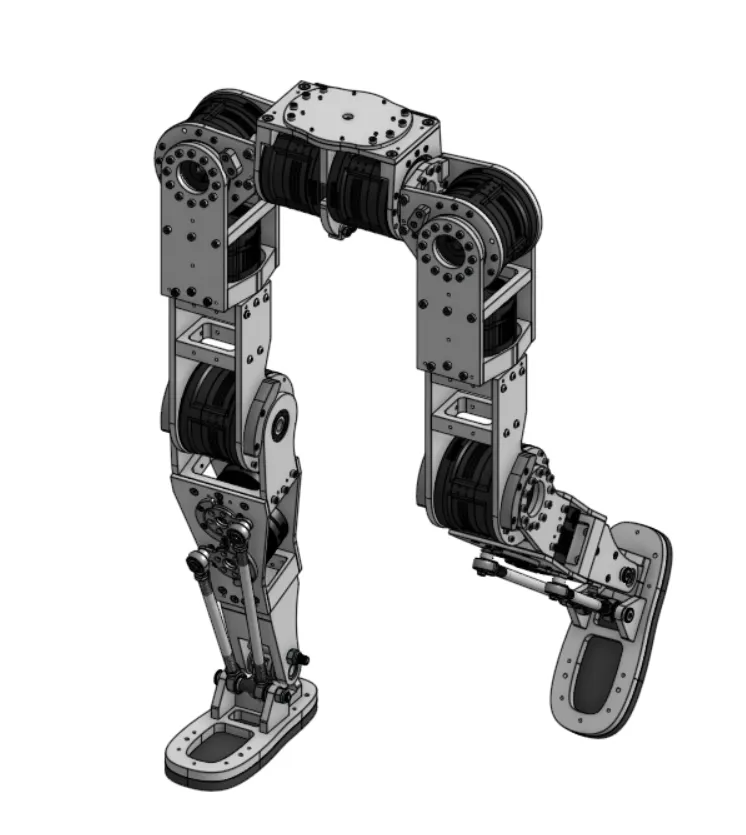
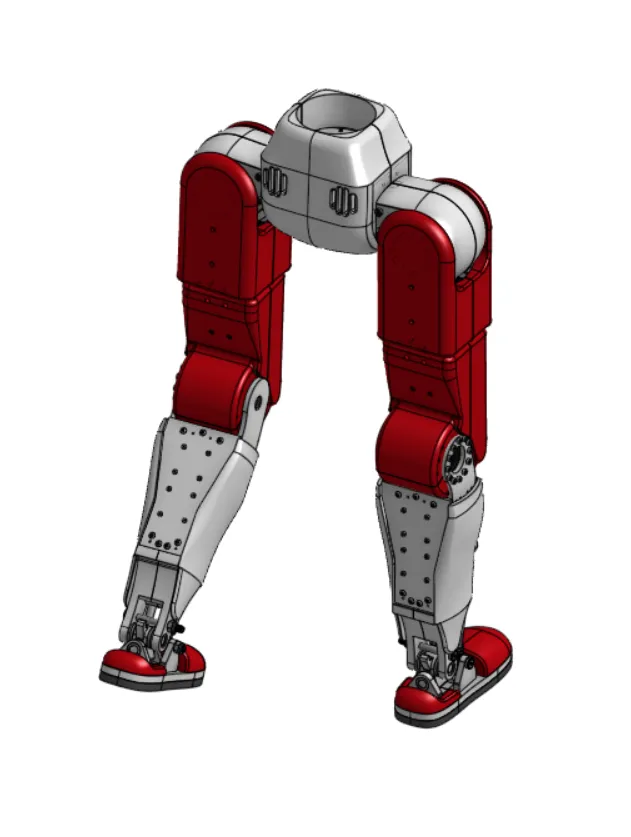
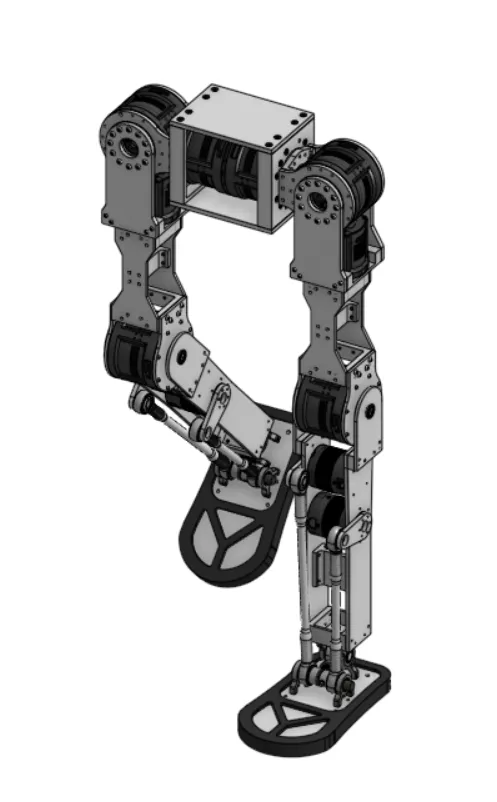
The Wisconsin Humanoid Club is working to become the first undergraduate team in the U.S. to build a working humanoid robot. After designing the arms and outer casing last spring, I now lead the 12-person Legs Team. Our goal is a full redesign of the 6-DOF legs that is machined, assembled, and walking by December.
Key contributions
Team leadership. Onboarded 11 new members, matched them to starter projects by skill, and set and enforce the sprint timeline.
Structural redesign. Replaced the large, material-wasteful CNC parts and imprecise sheet metal with small, simple machined blocks paired with plates. The design uses more parts but is modular, cheaper to machine, and makes broken parts easy to swap. Dowel pins keep alignment repeatable across reassemblies to limit drift during training.
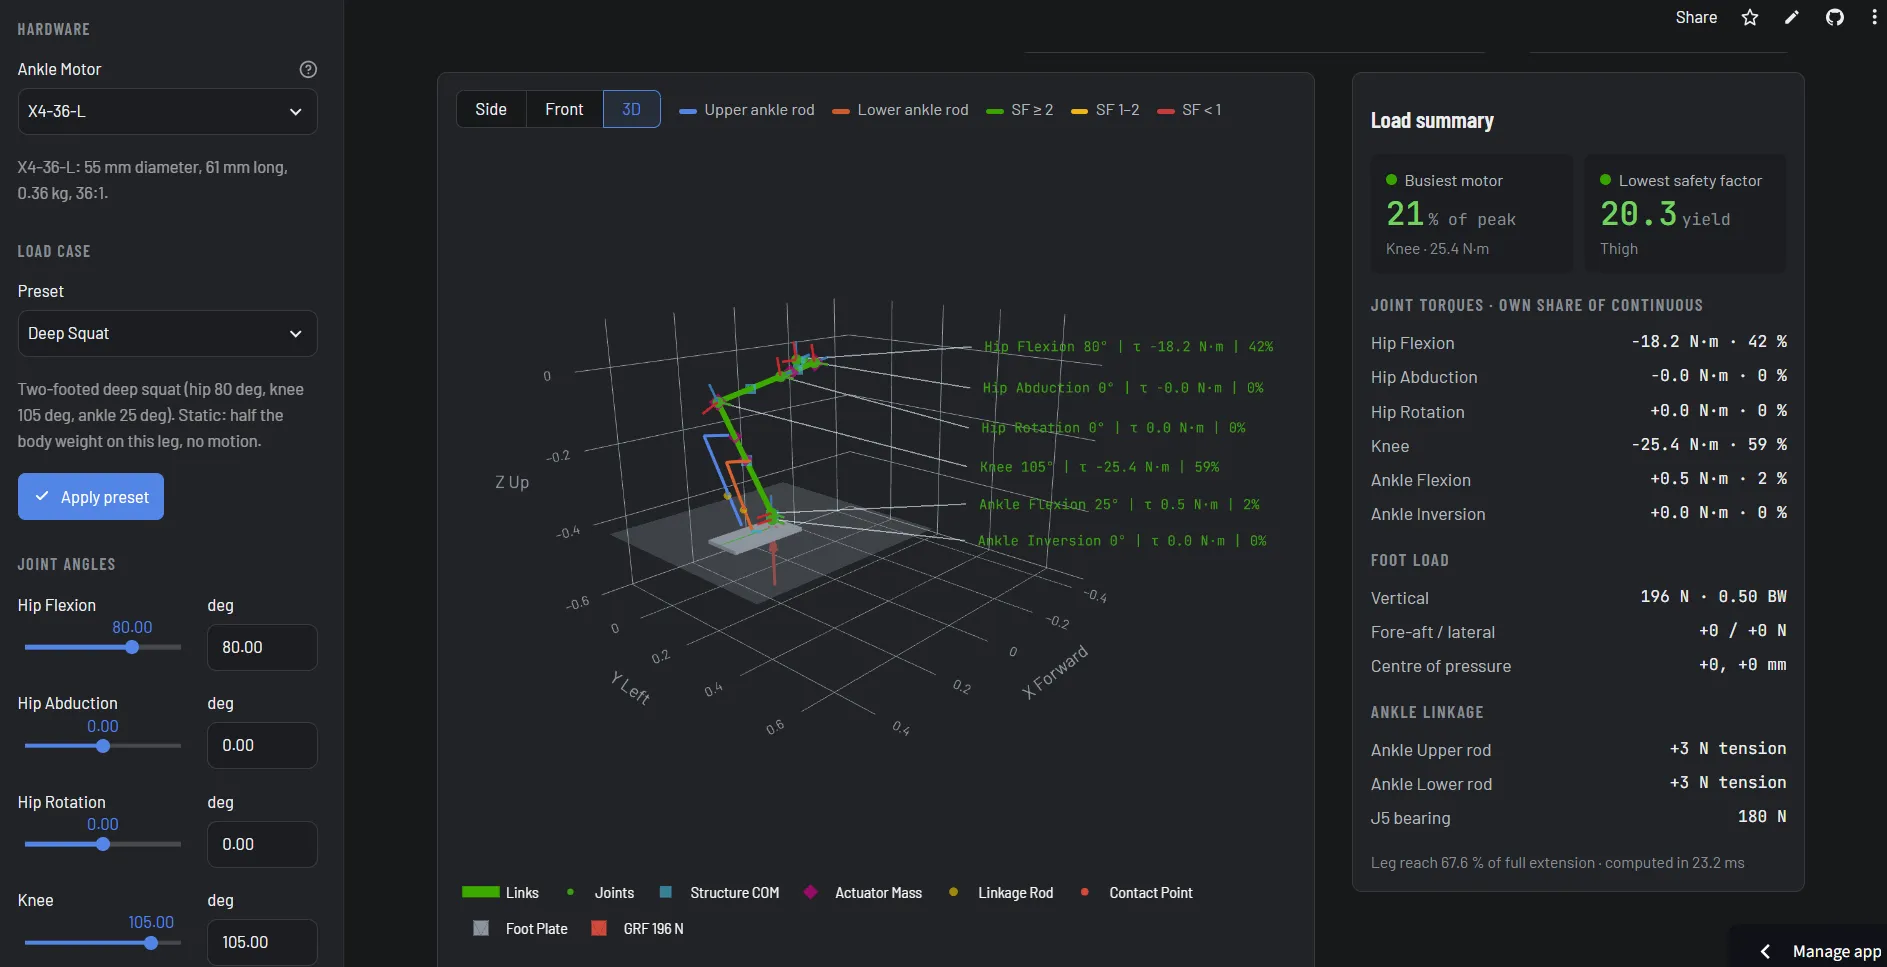
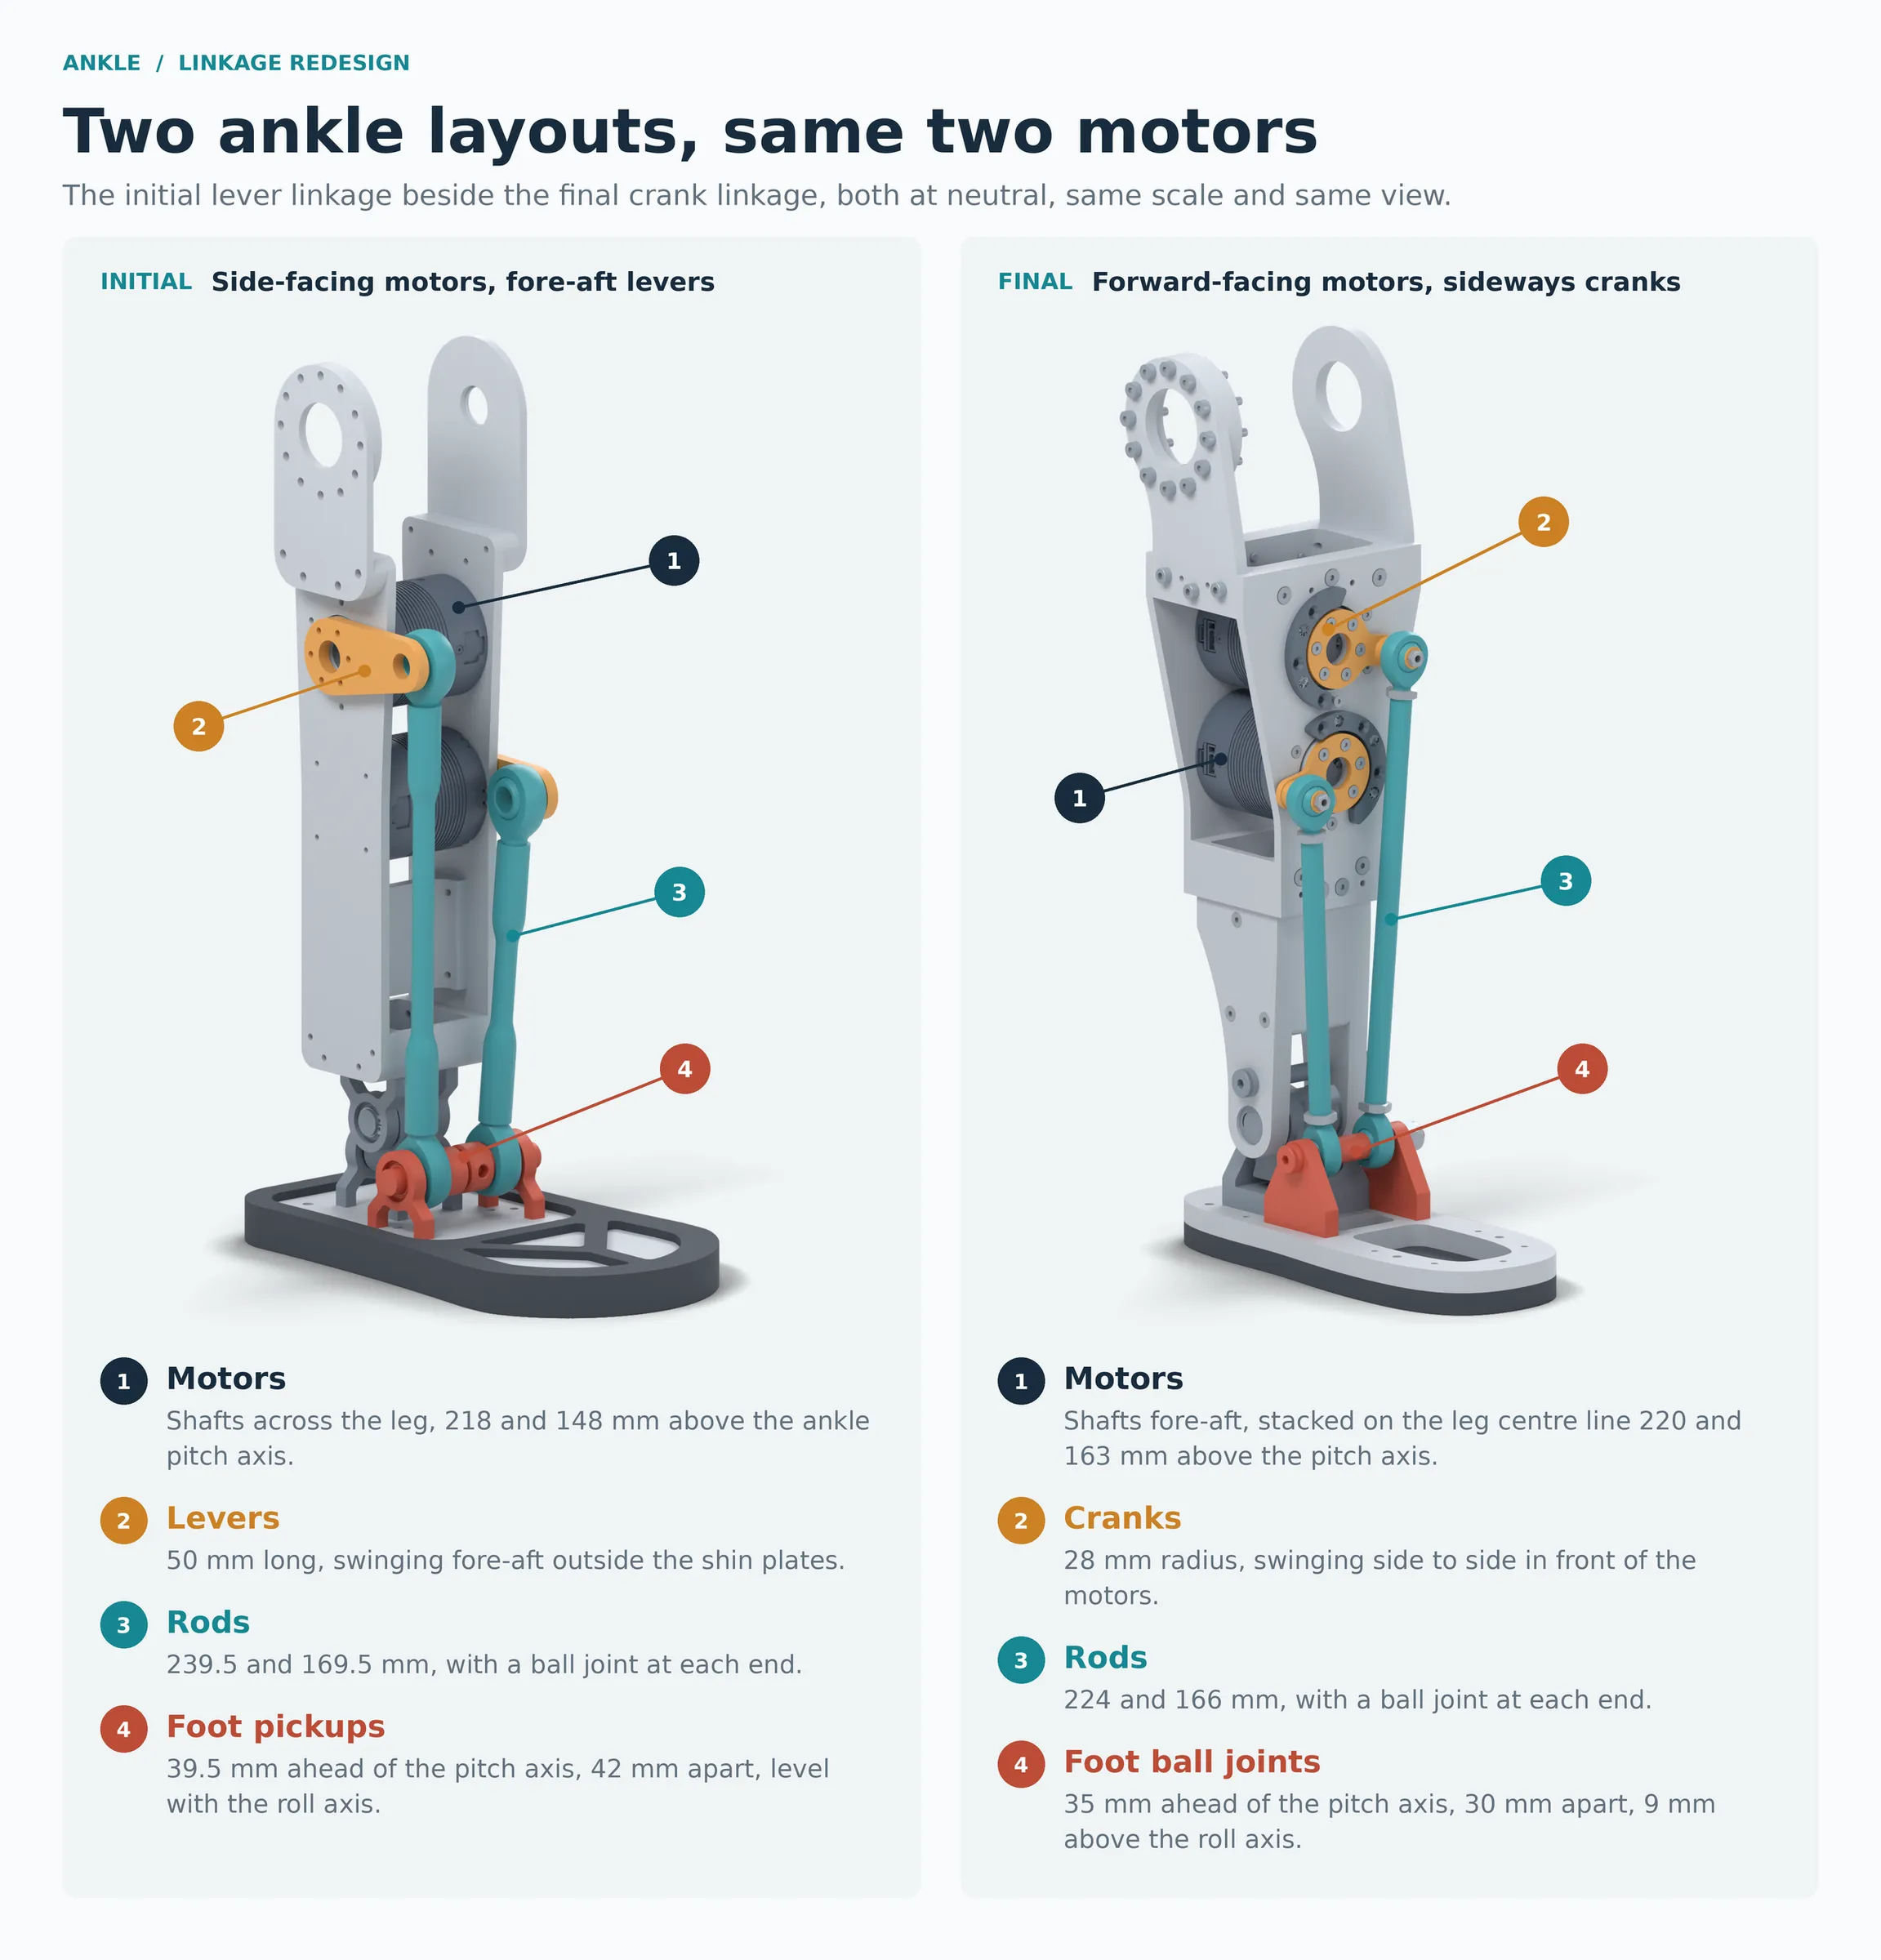
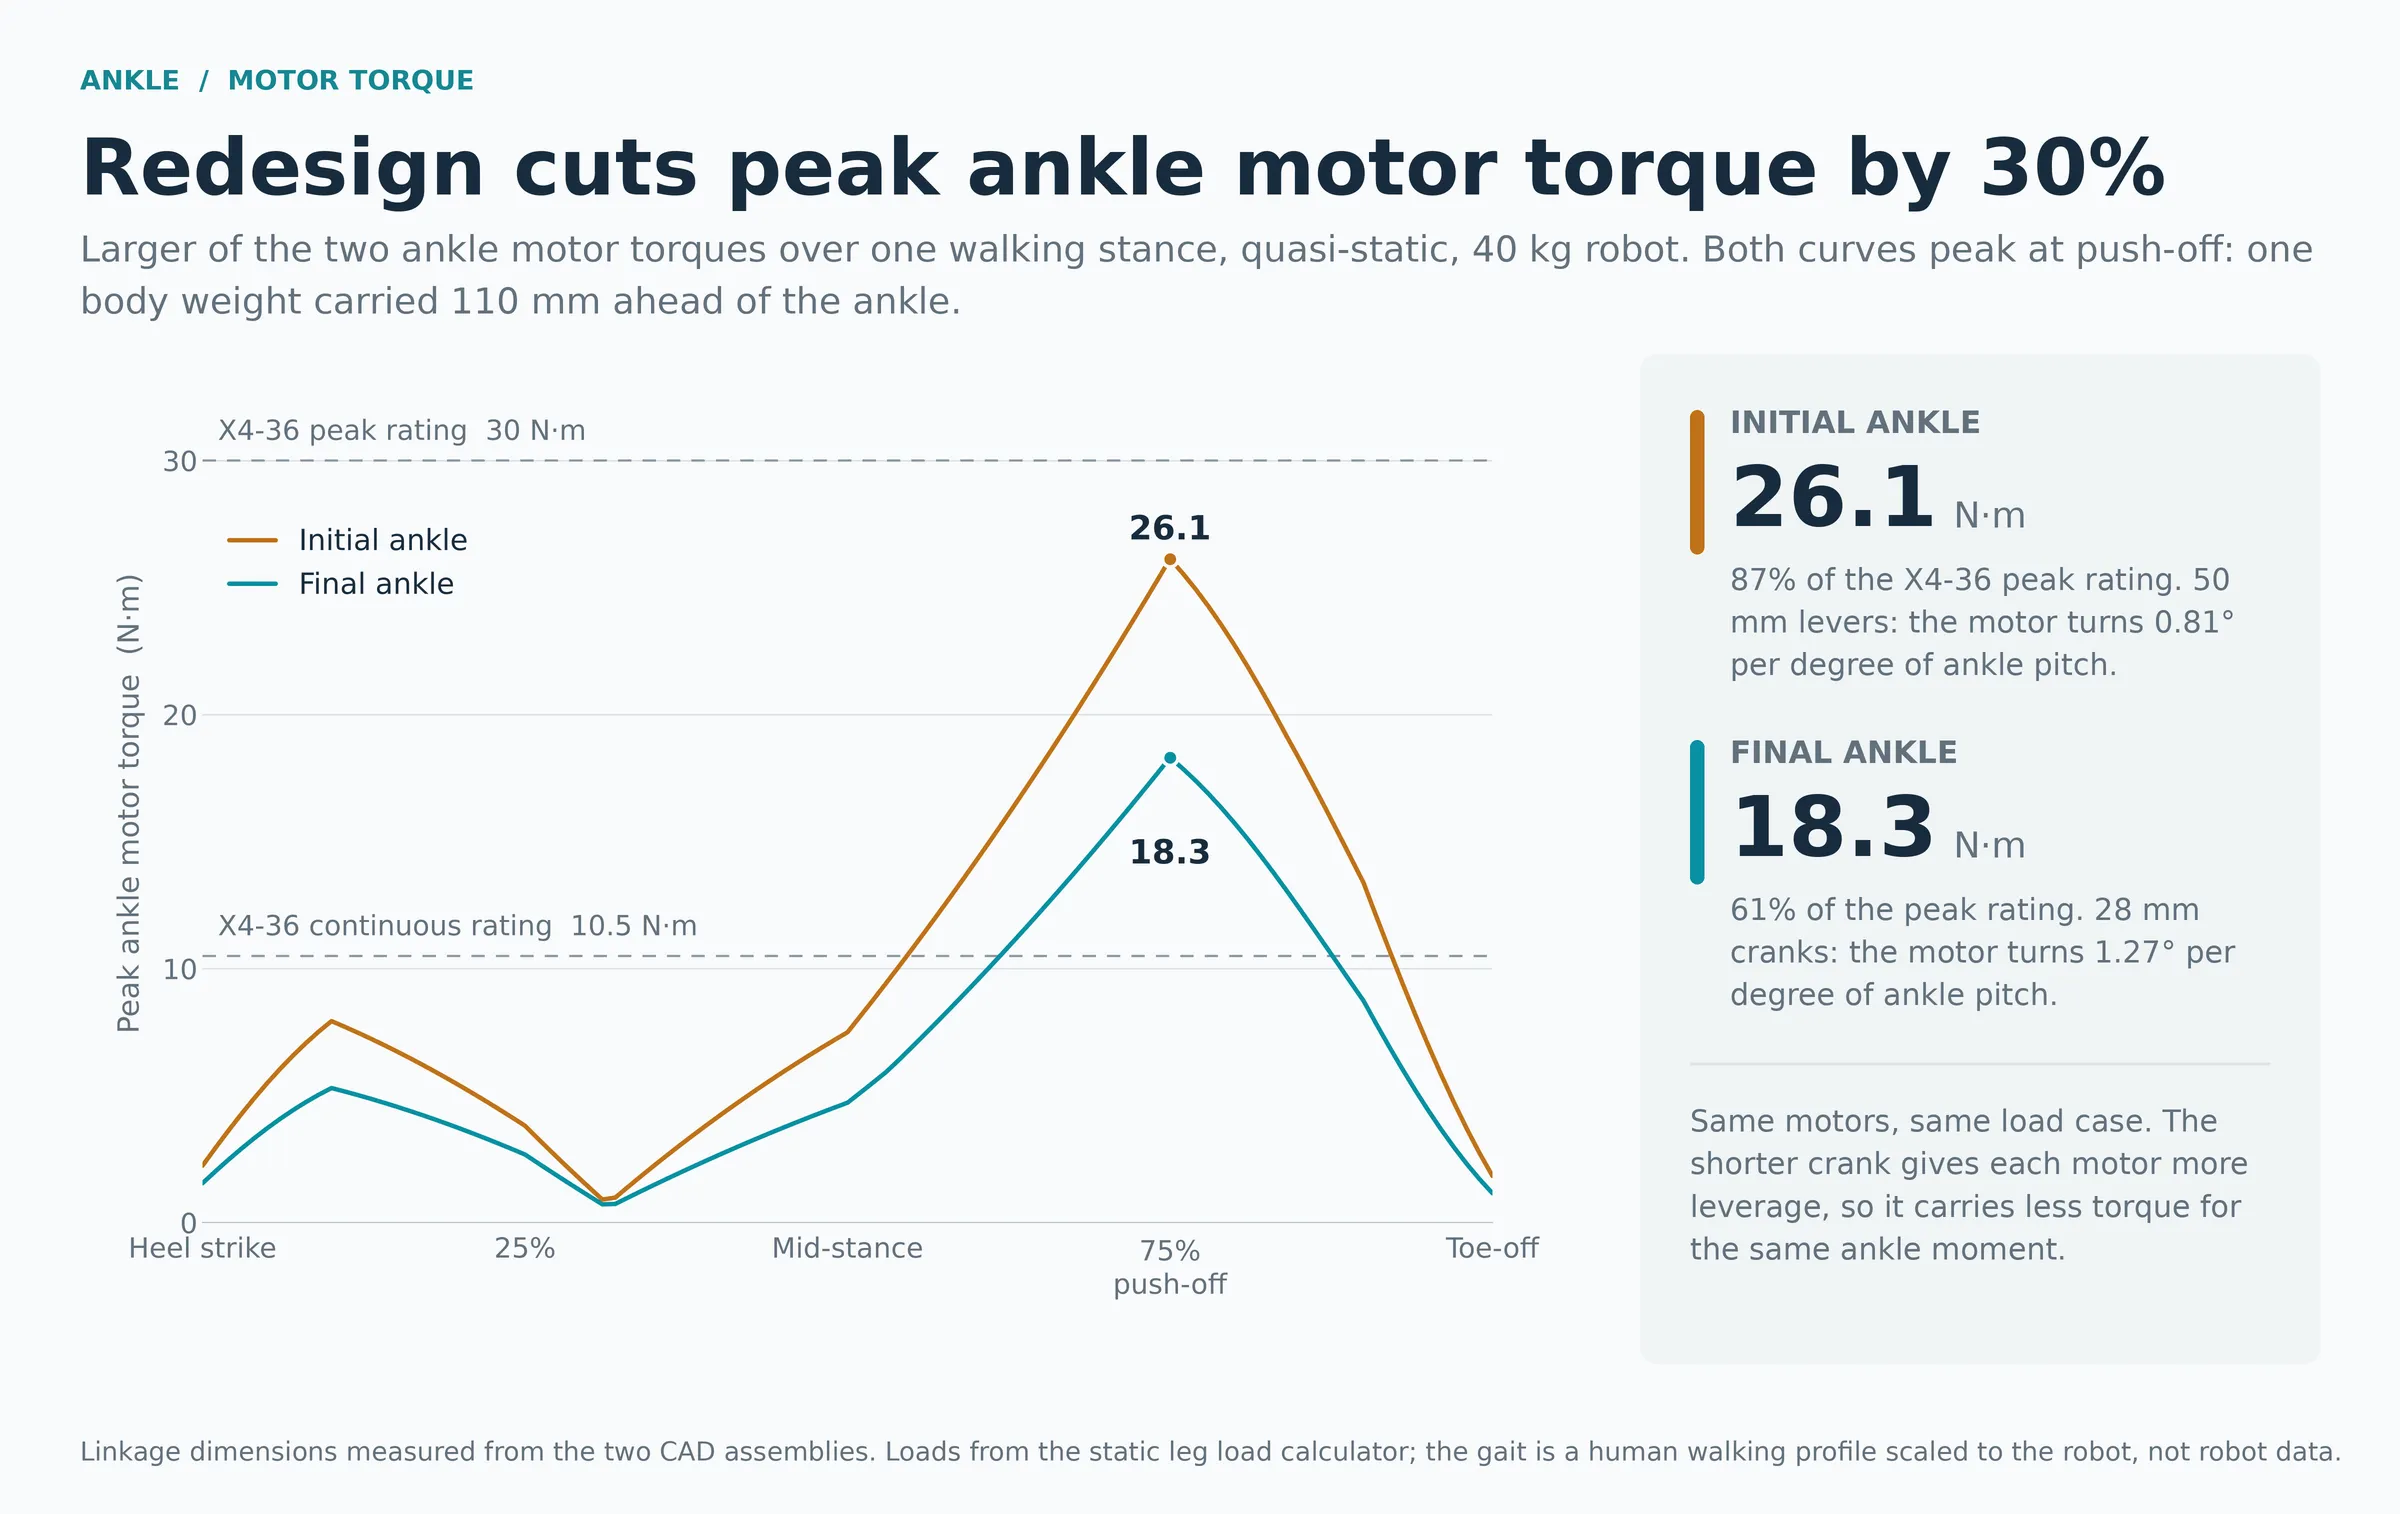
Load analysis. Built a web-based static load calculator to check actuator torque across leg poses. When an alternate ankle linkage designed to avoid actuator collisions proved weak, and its large linkages risked slop, the calculator let us quickly verify a return to a parallel linkage. This helped us better understand our design tradeoffs, and cut our estimated peak motor torques by 30%.
Sourcing and manufacturing. Sourcing off-the-shelf and custom-machined parts for the aluminum prototype, balancing cost against lead time.
Status (November 2026)
V1 design finished and toleranced for manufacturing. Custom and off-the-shelf parts ordered. Assembly and motion testing in early December.