Rover Wheel
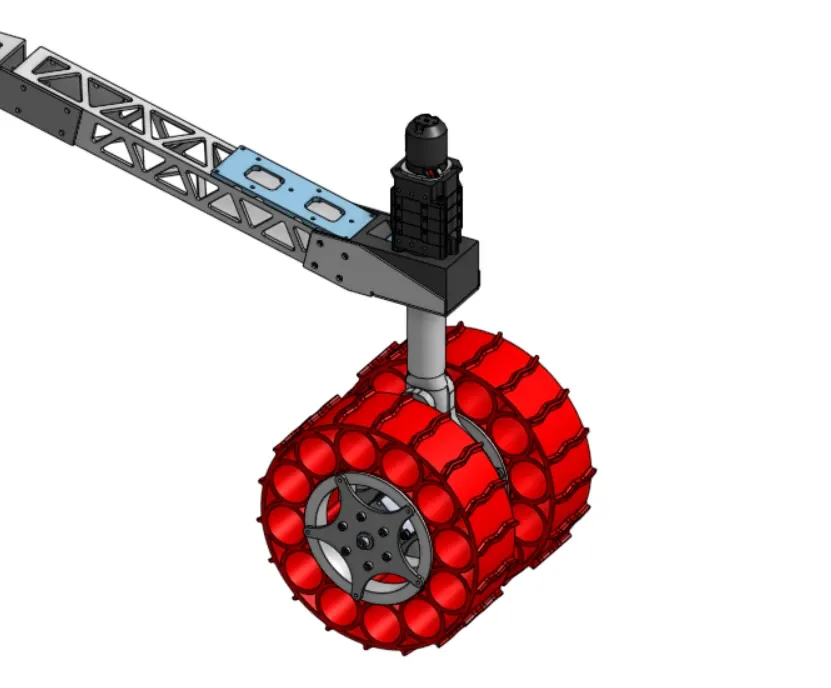
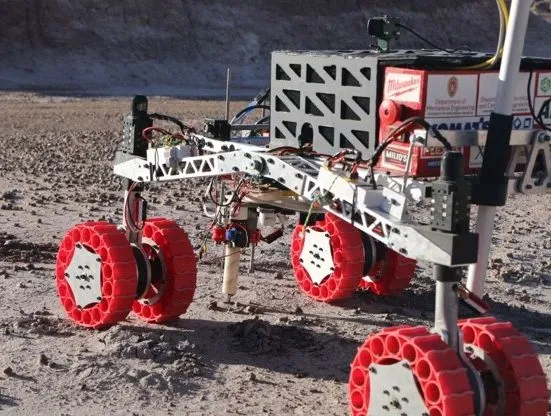
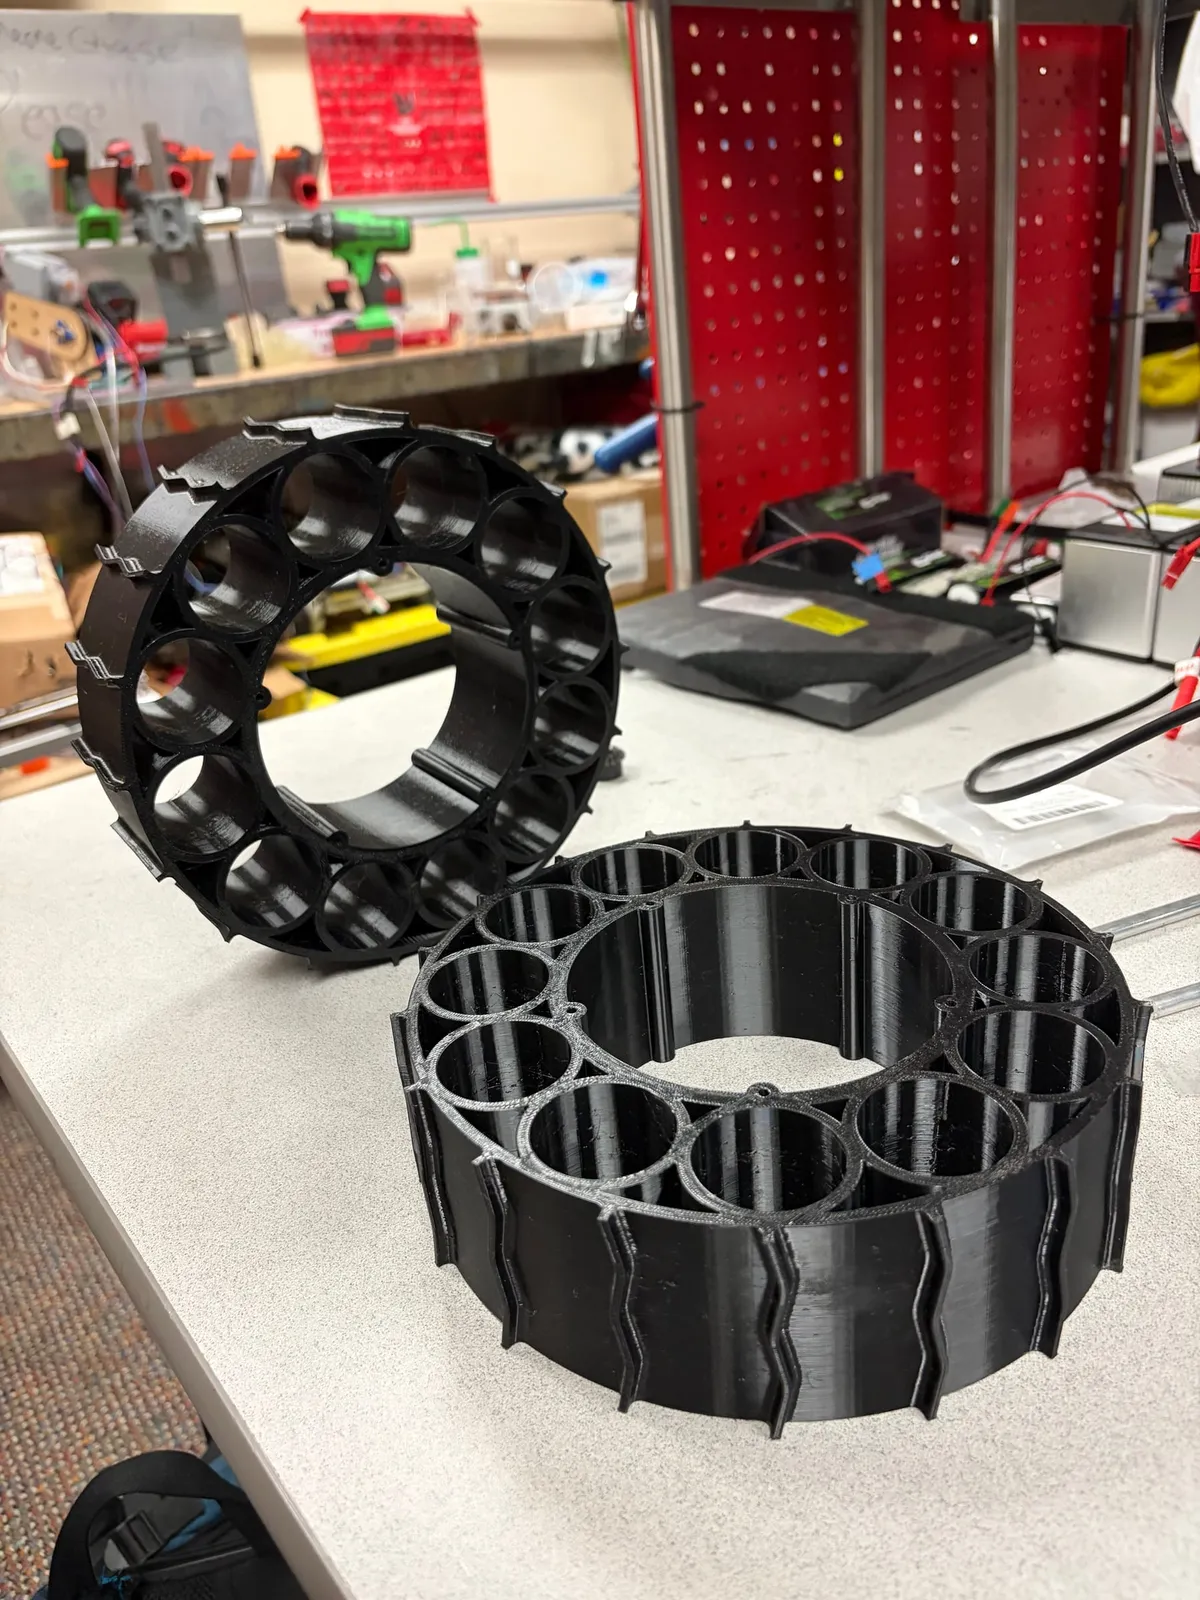
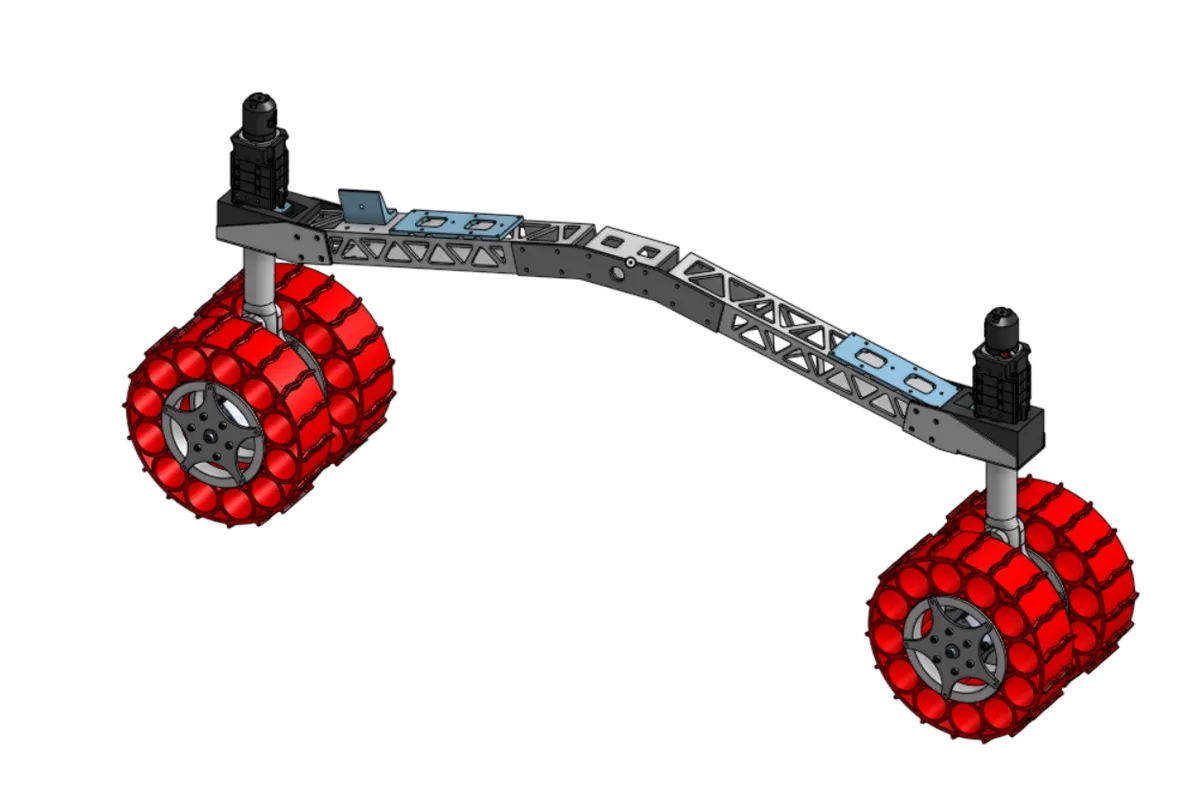
To address traction failure and vibration issues encountered during the previous University Rover Challenge (URC), I designed a compliant wheel system for our 2026 rover. While last year’s rigid wheels struggled with slip and impact on high-relief rocky terrain, this year’s iteration focuses on mechanical deformation to improve surface contact.
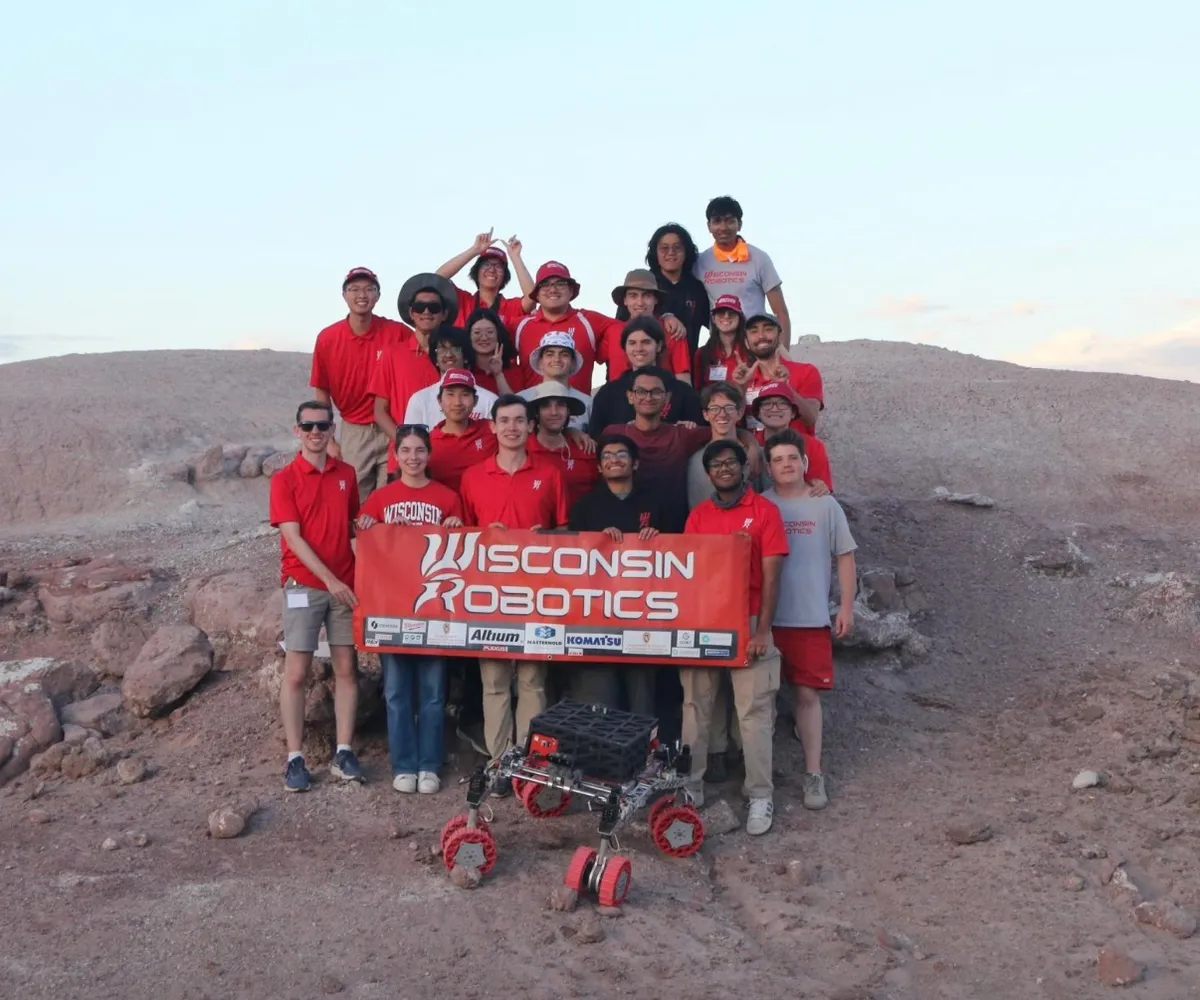
The rover placed 12th overall out of the 36 teams selected to compete in this year’s competition.
Key contributions
Architectural research. Evaluated various URC-specific wheel geometries to balance weight, durability, and grip.
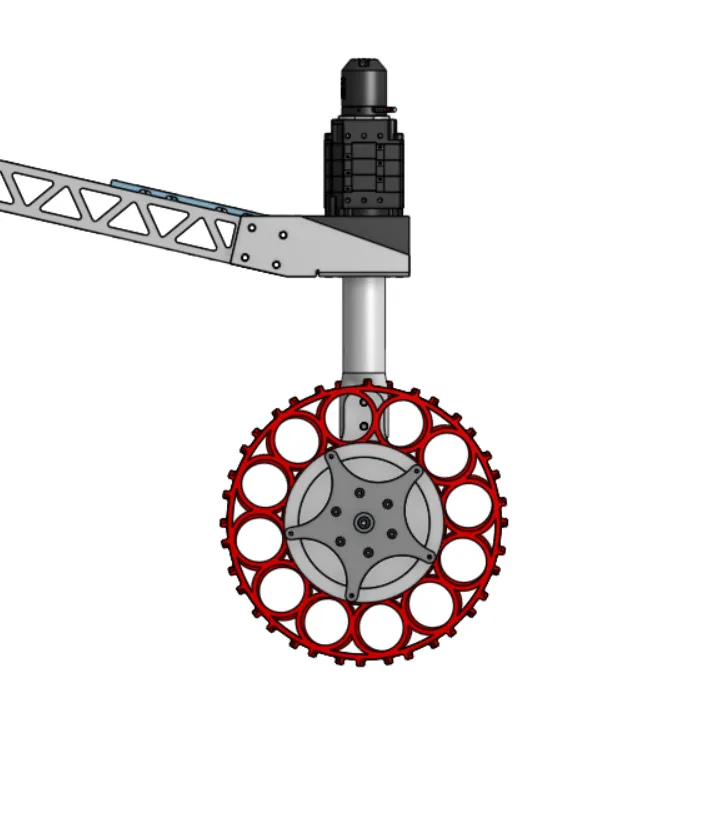
Improved geometry. Developed a lightweight frame utilizing a radial array of small cylinders to provide structural integrity while allowing for localized deflection.
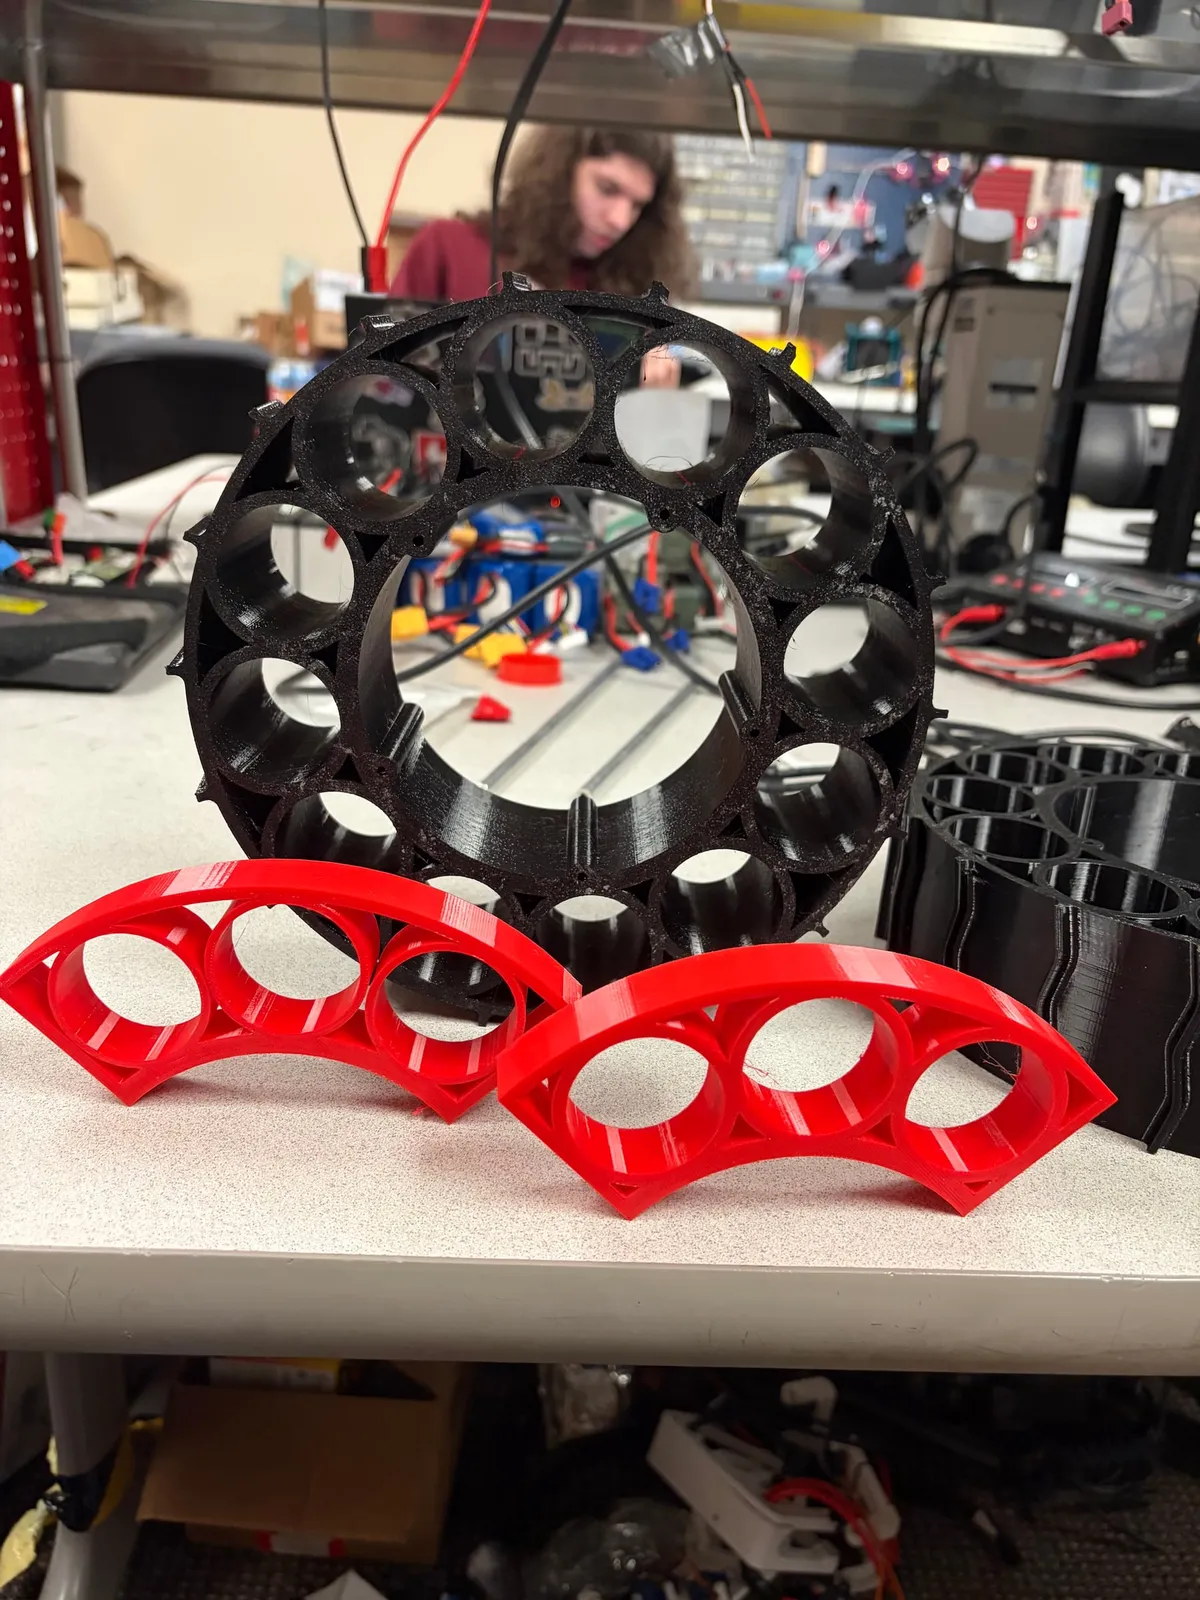
Easy fabrication. Optimized the design for 3D printing in TPU 95A, achieving significant mass reduction without sacrificing load-bearing capacity.
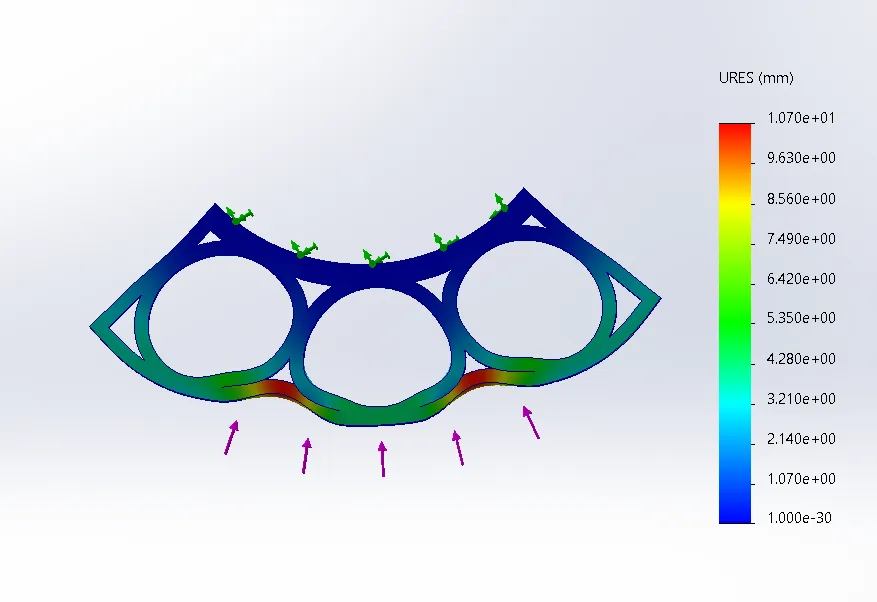
Validation. Conducted iterative FEA and physical testing on 3D-printed sub-sections to fine-tune compliance and deformation rates under simulated rover loads.